RAH-66 Comanche maintenance event.
 Butch W.
Lets do this.
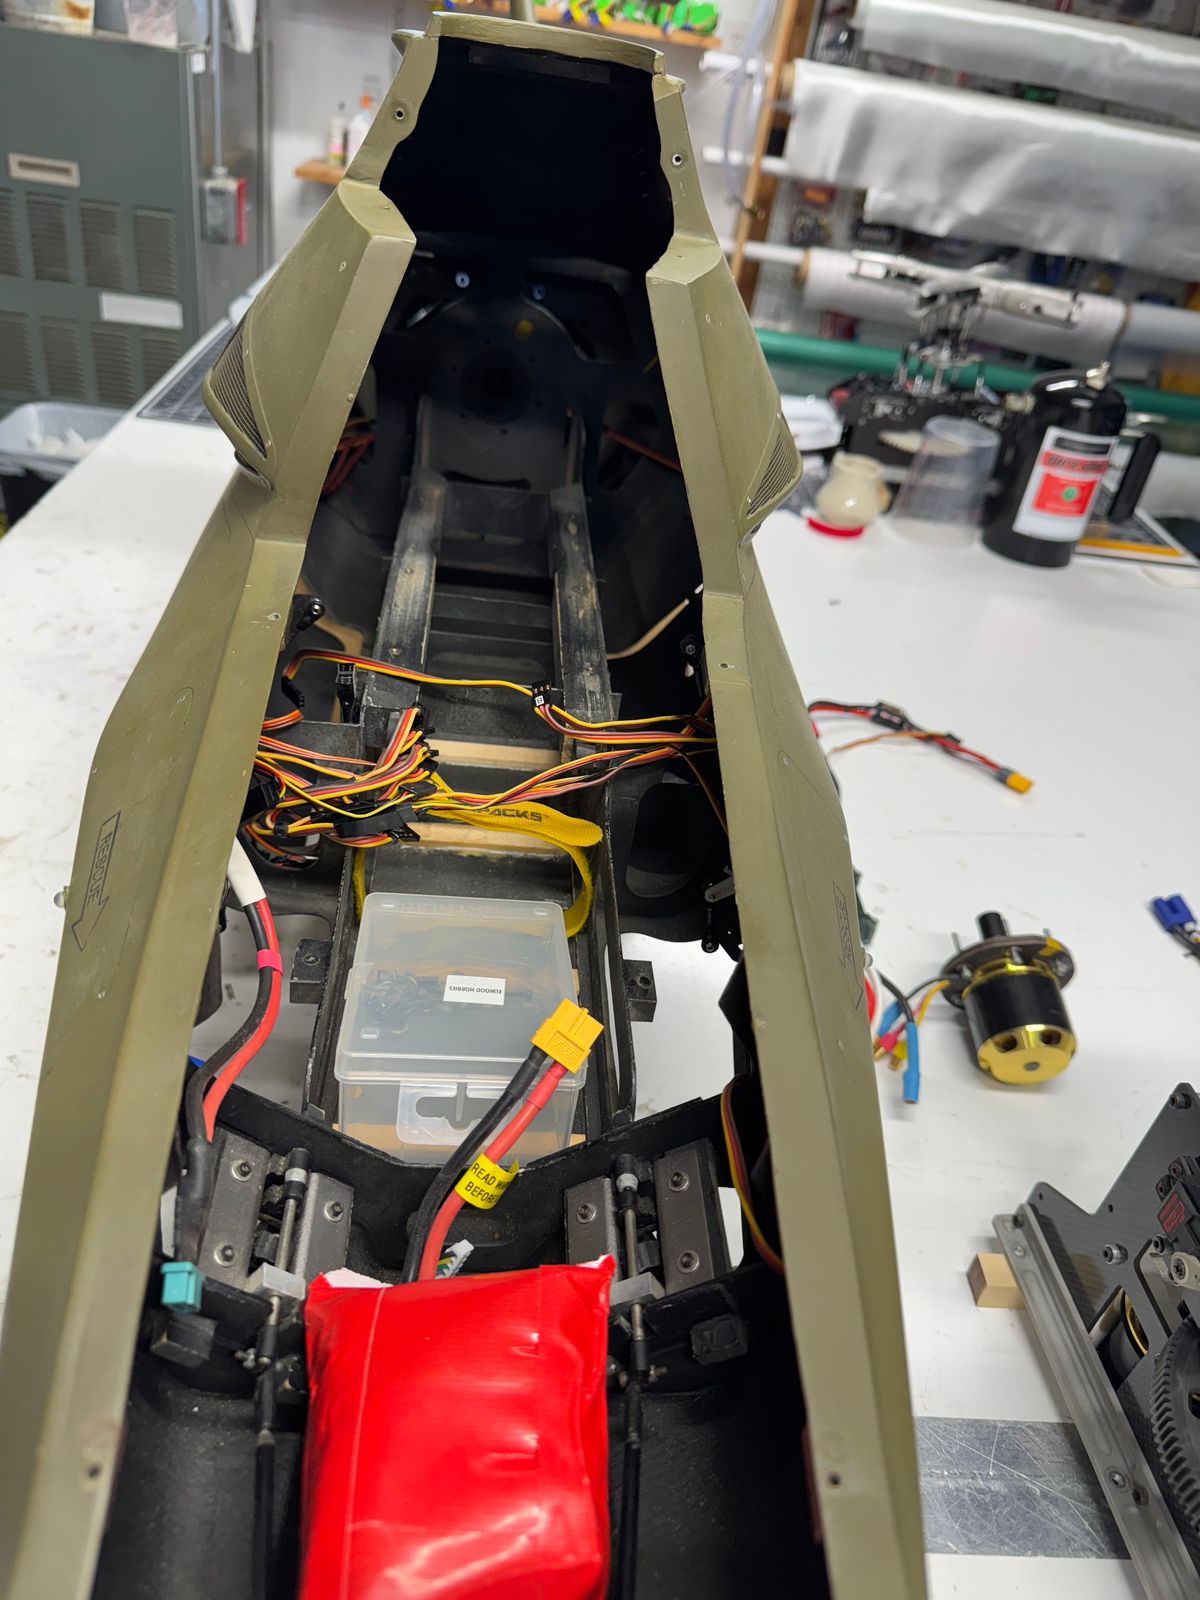
It’s time to get aircraft ready for the flying season. Most in the hangar are ready for the season however “Homer” likes a little more maintenance than the others. With running duel motors, and ESC’s along with all the parts to hook everything together and then, for it all to actually work as one harmonious flying machine has been a daunting task.
This is actually my second Comanche. The first one was nitro powered. It looked great but lacked in performance. It would hover around but lacked in tail authority to become a viable flying machine. It ultimately met its demise which was a god send.
I was able to acquire another fuse from Joe Howard about 15 years ago. I set it on the shelf and began thinking of all the things that did not work and how to make changes to make it work.
This machine has been flying for 13 years. Over this years I do the annual maintenance around this time. It is a very solid running and flying heli but does require a little more attention than most. I figured I would share this maintenance event with my fellow modelers so you can get an inside look at what make this thing work.
Hope you all enjoy and thanks for dropping by,
B
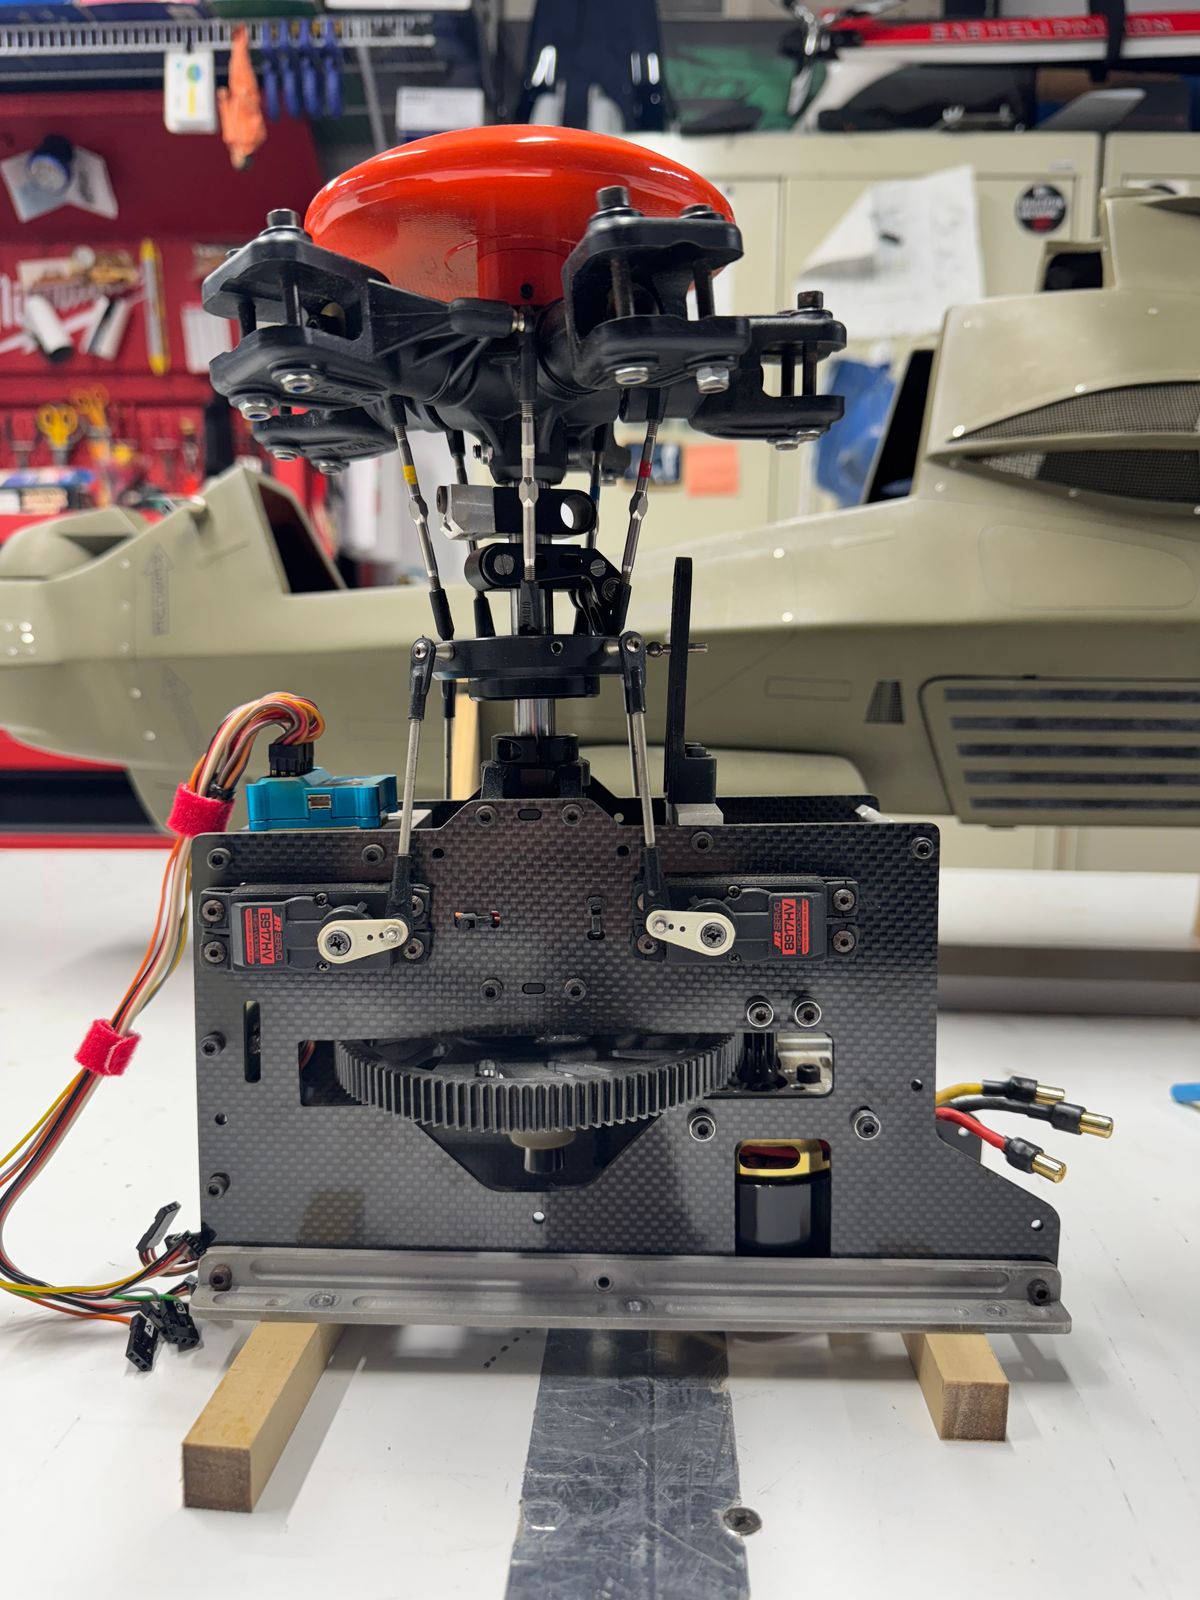
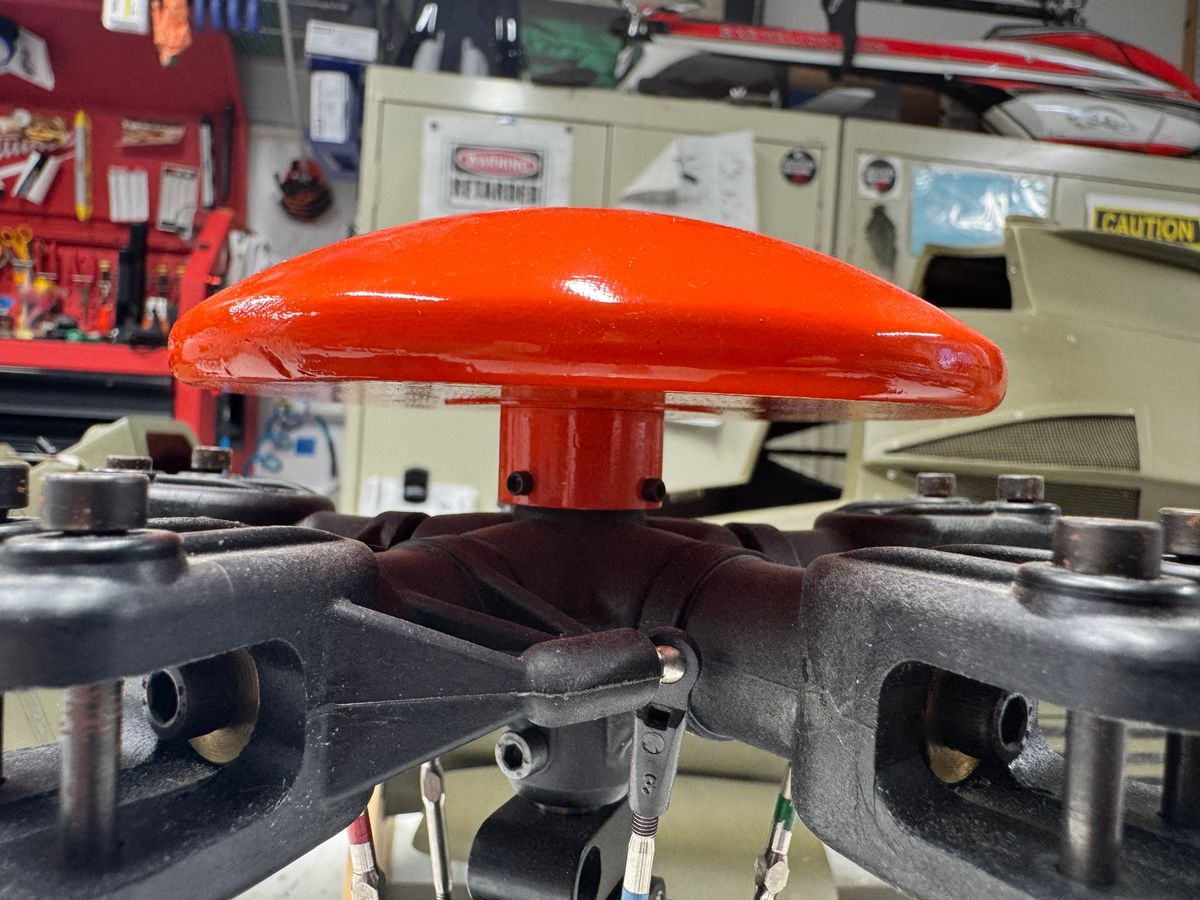
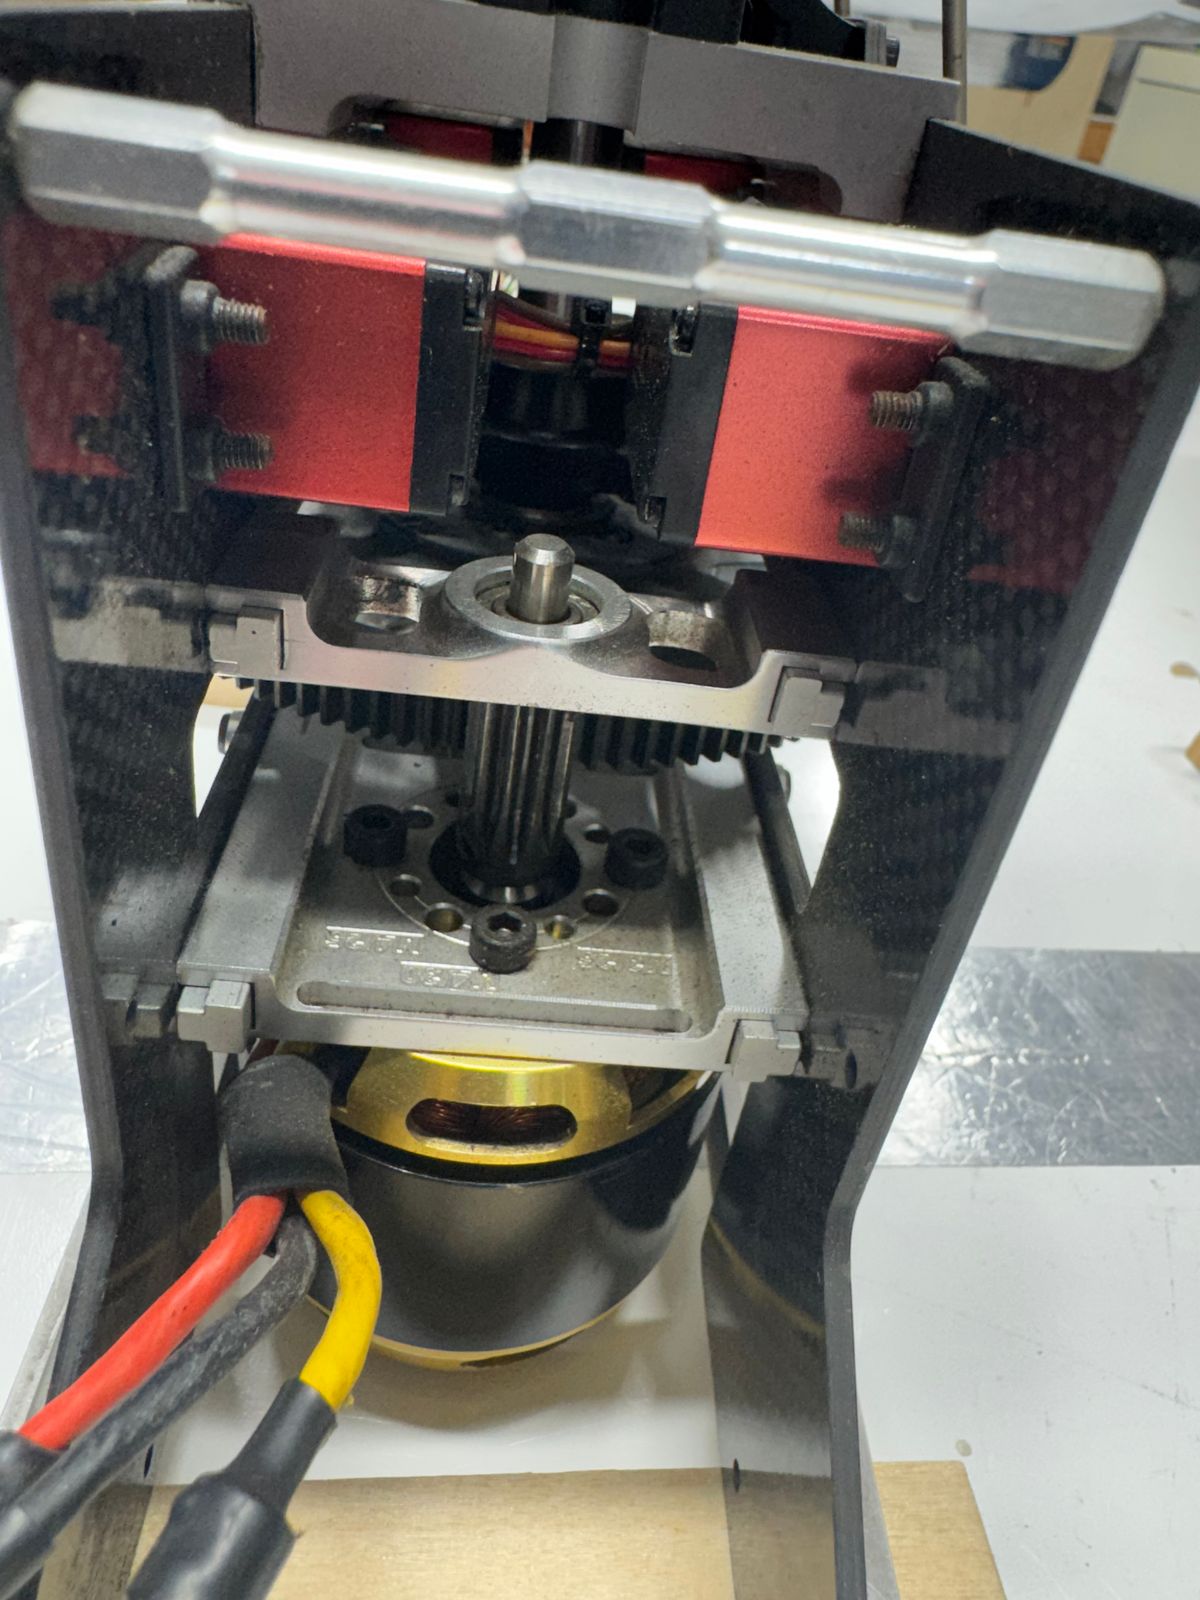
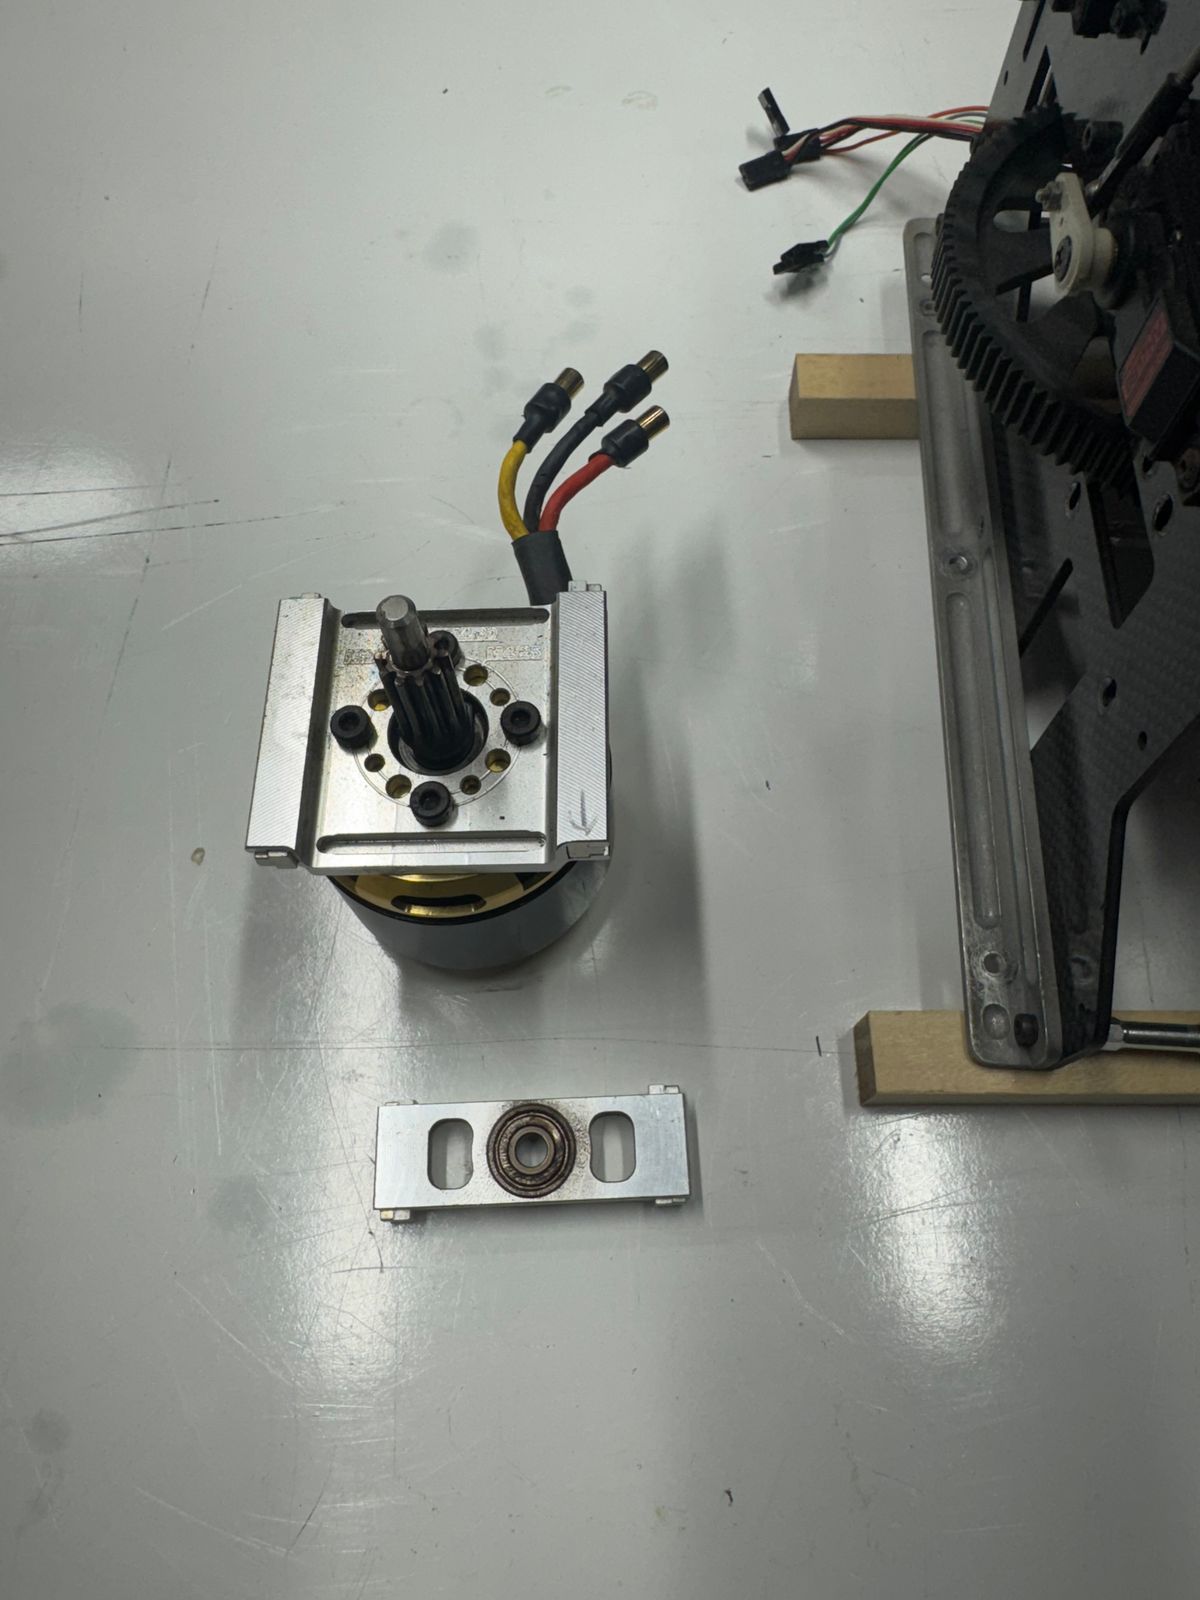
Maintenance Status.
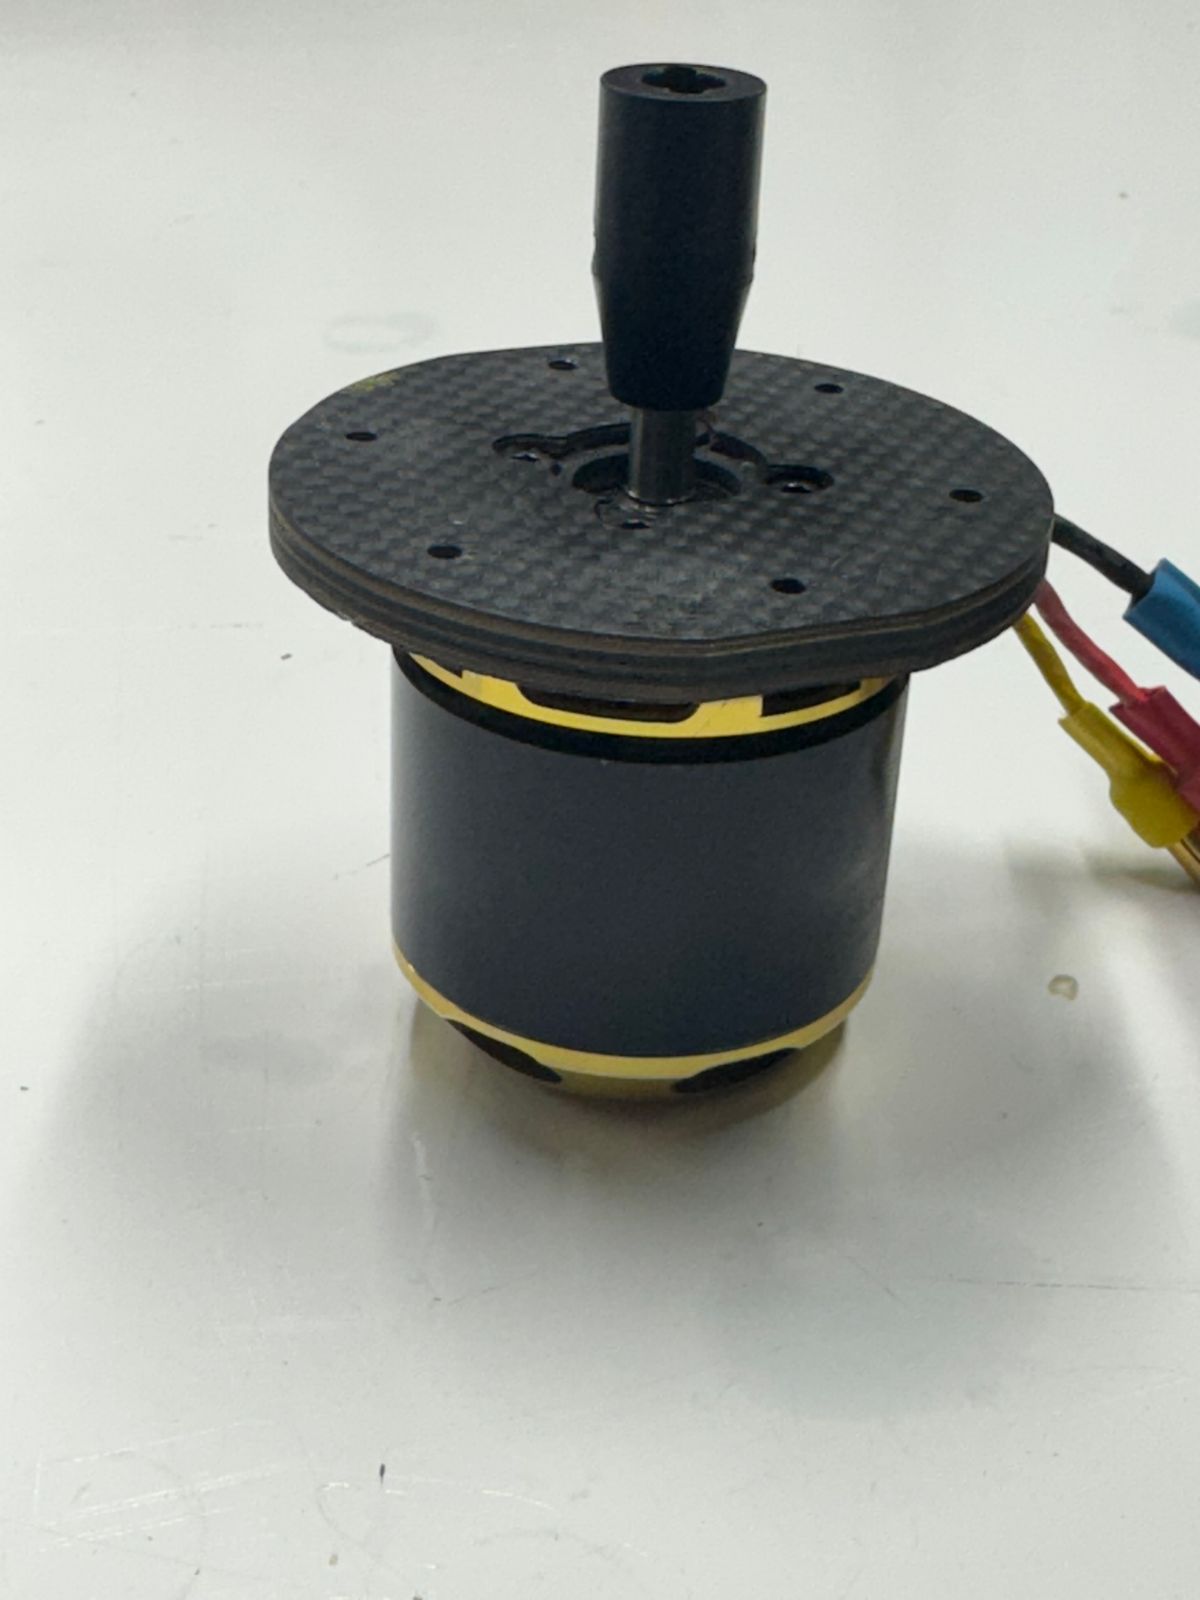
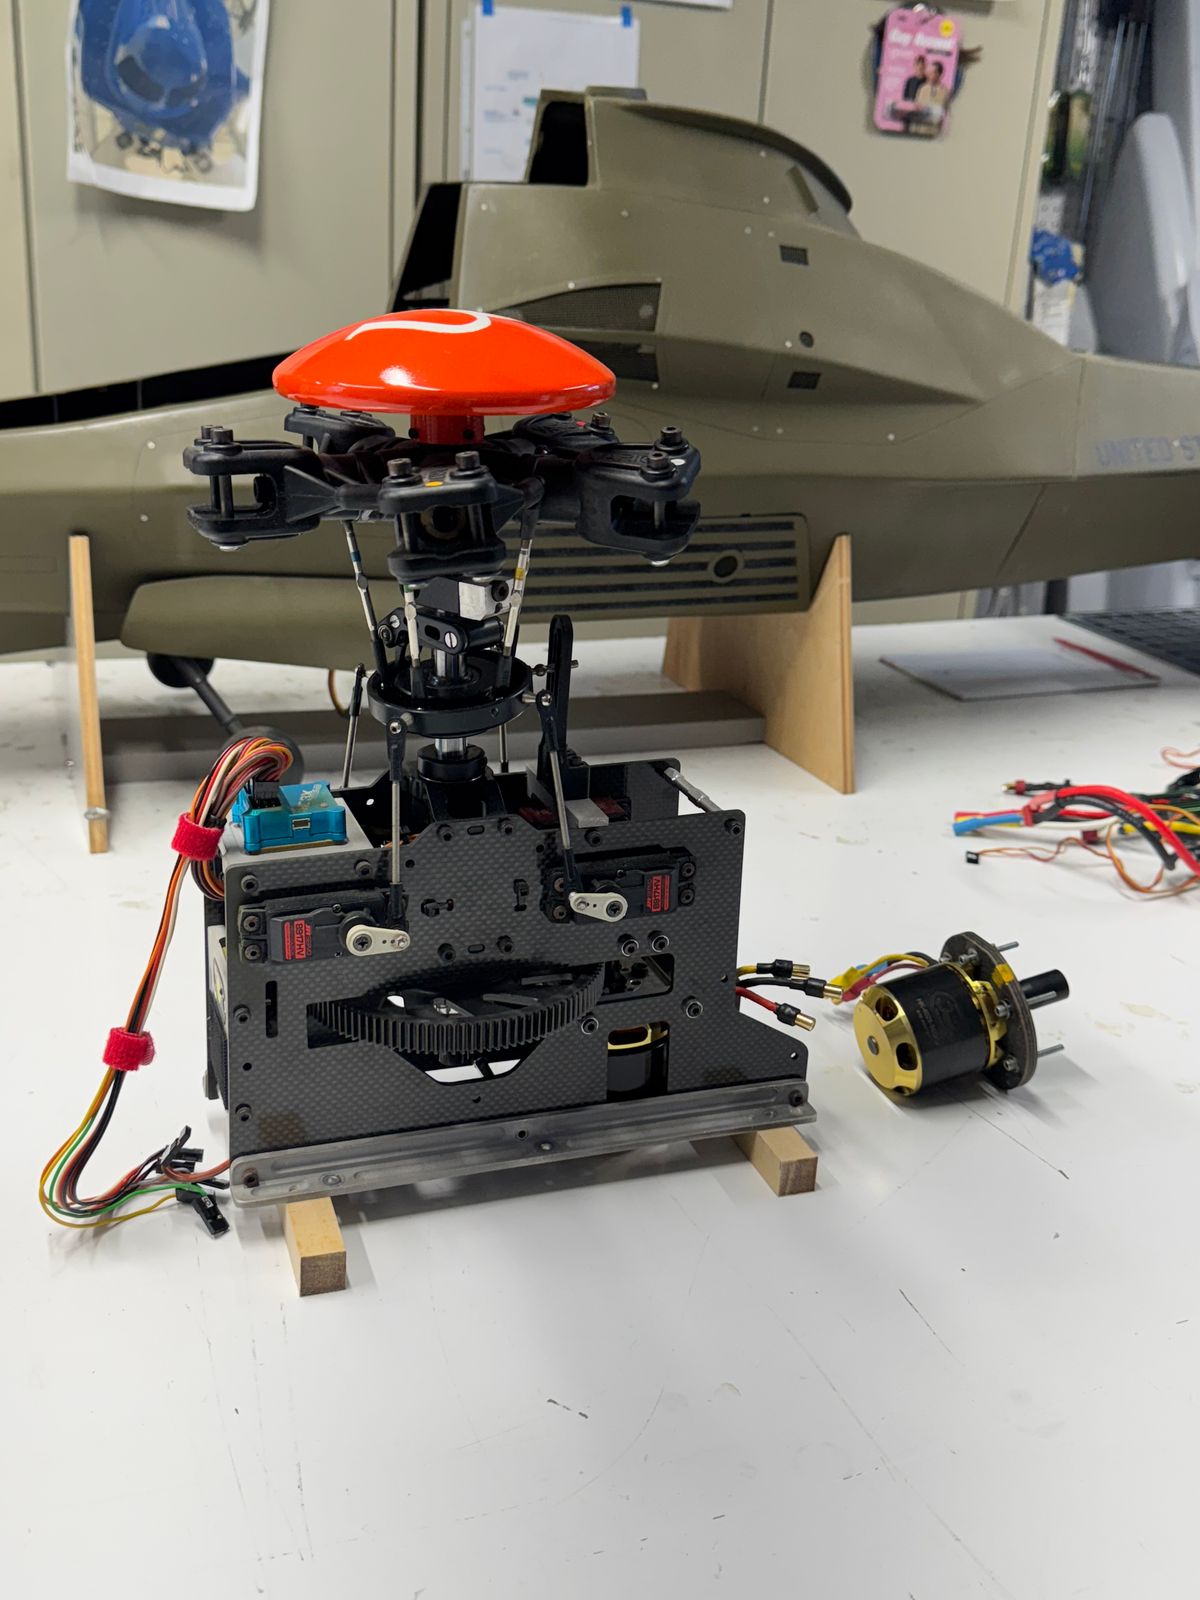
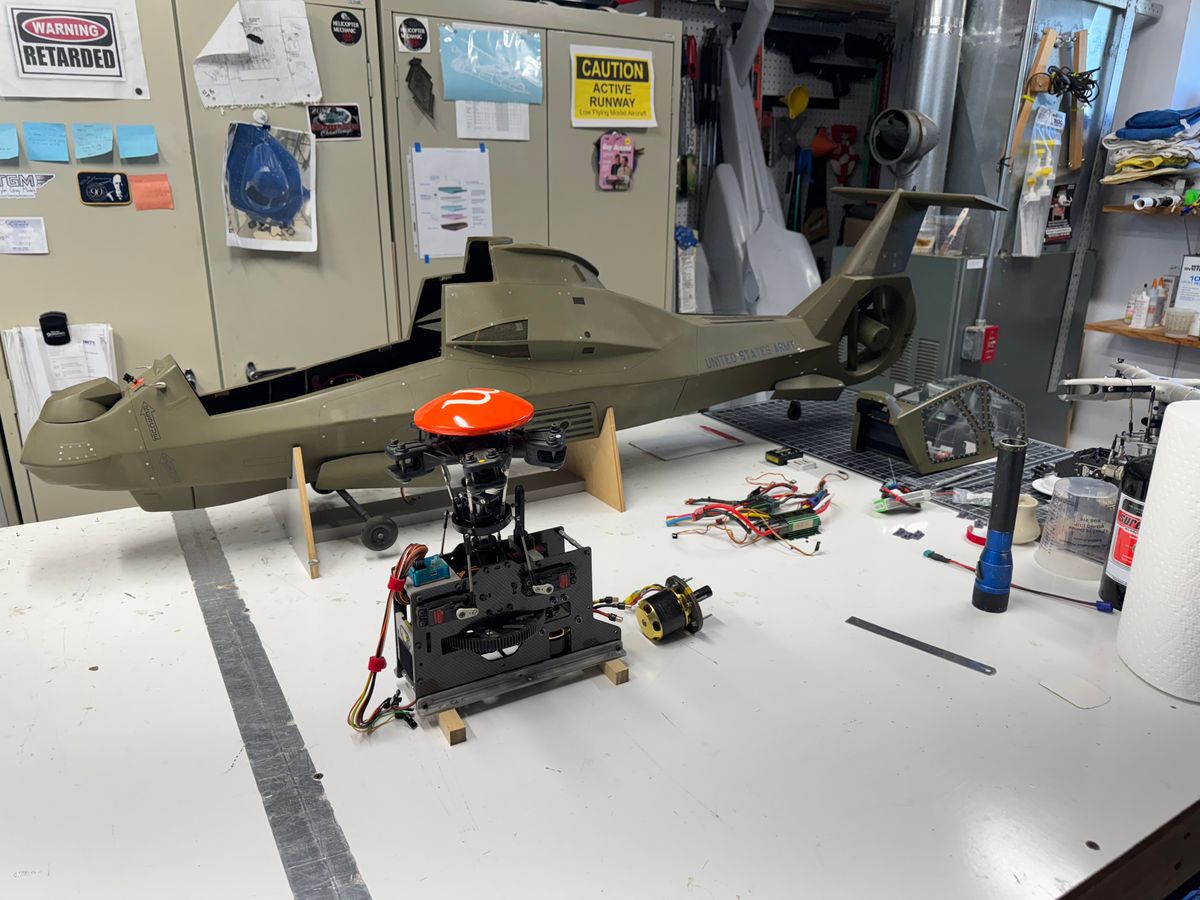
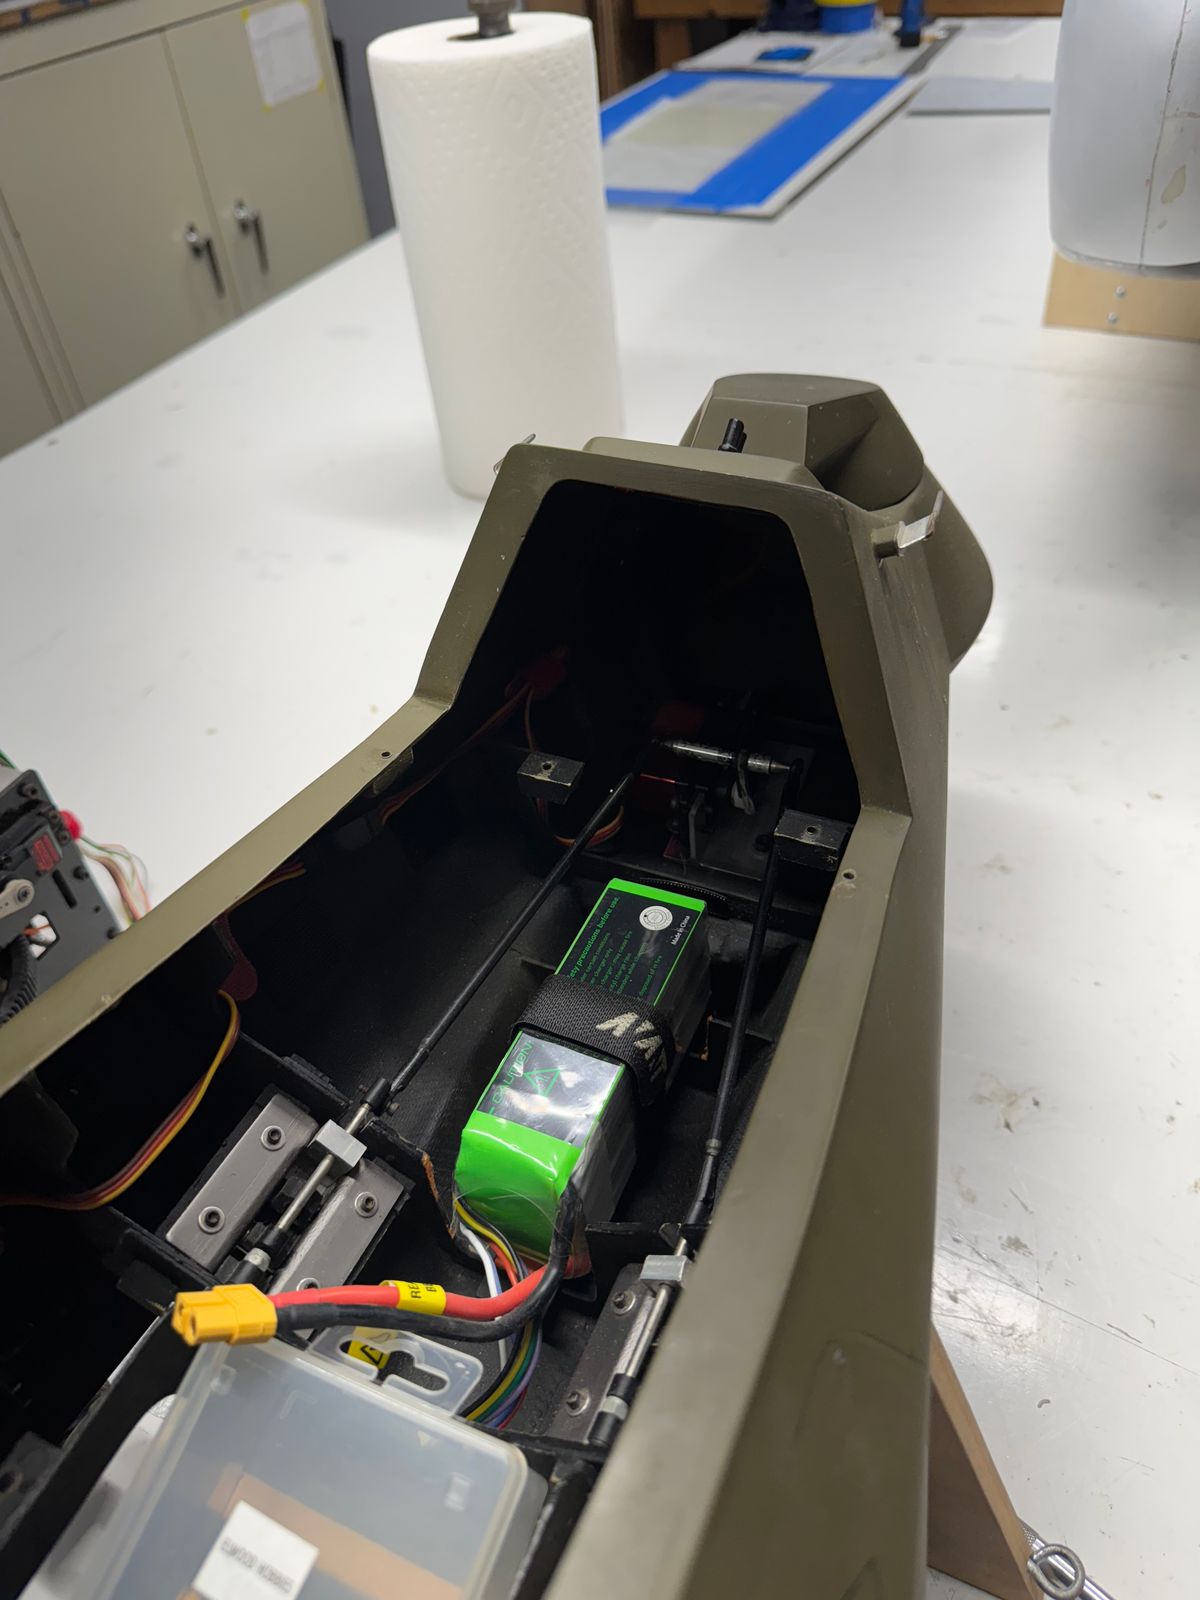
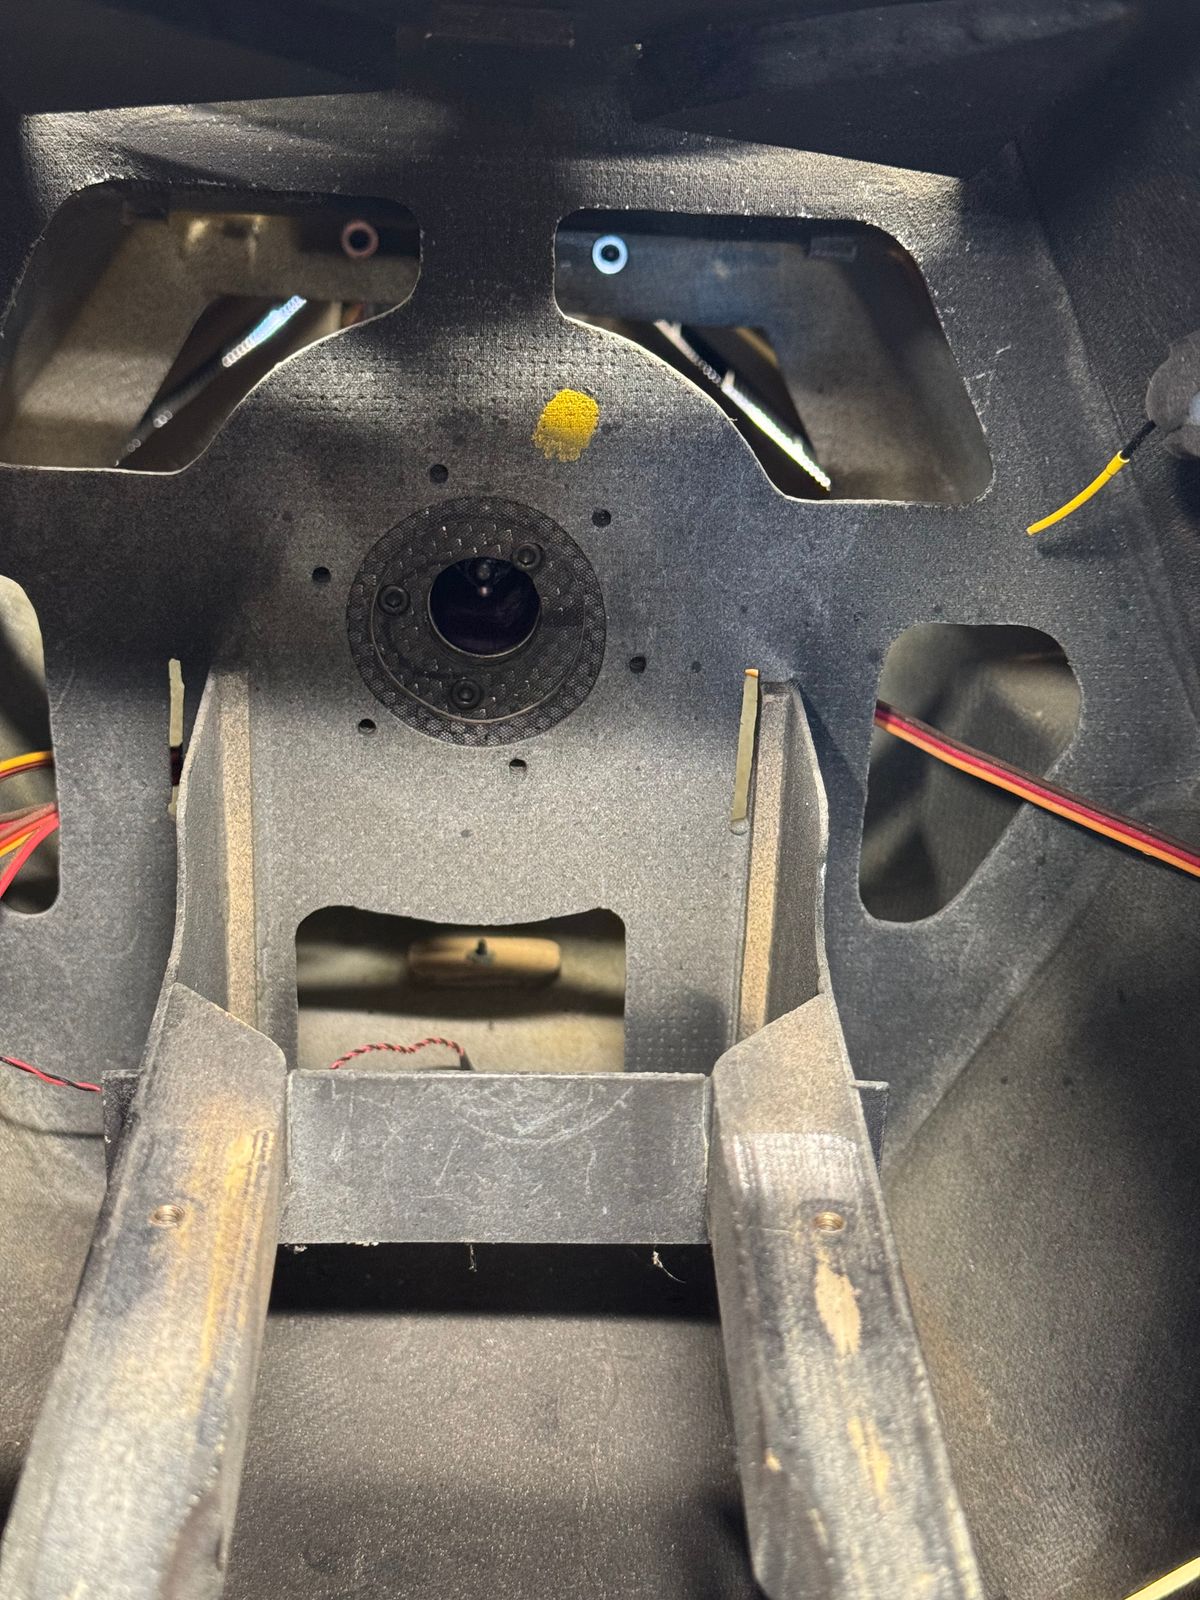
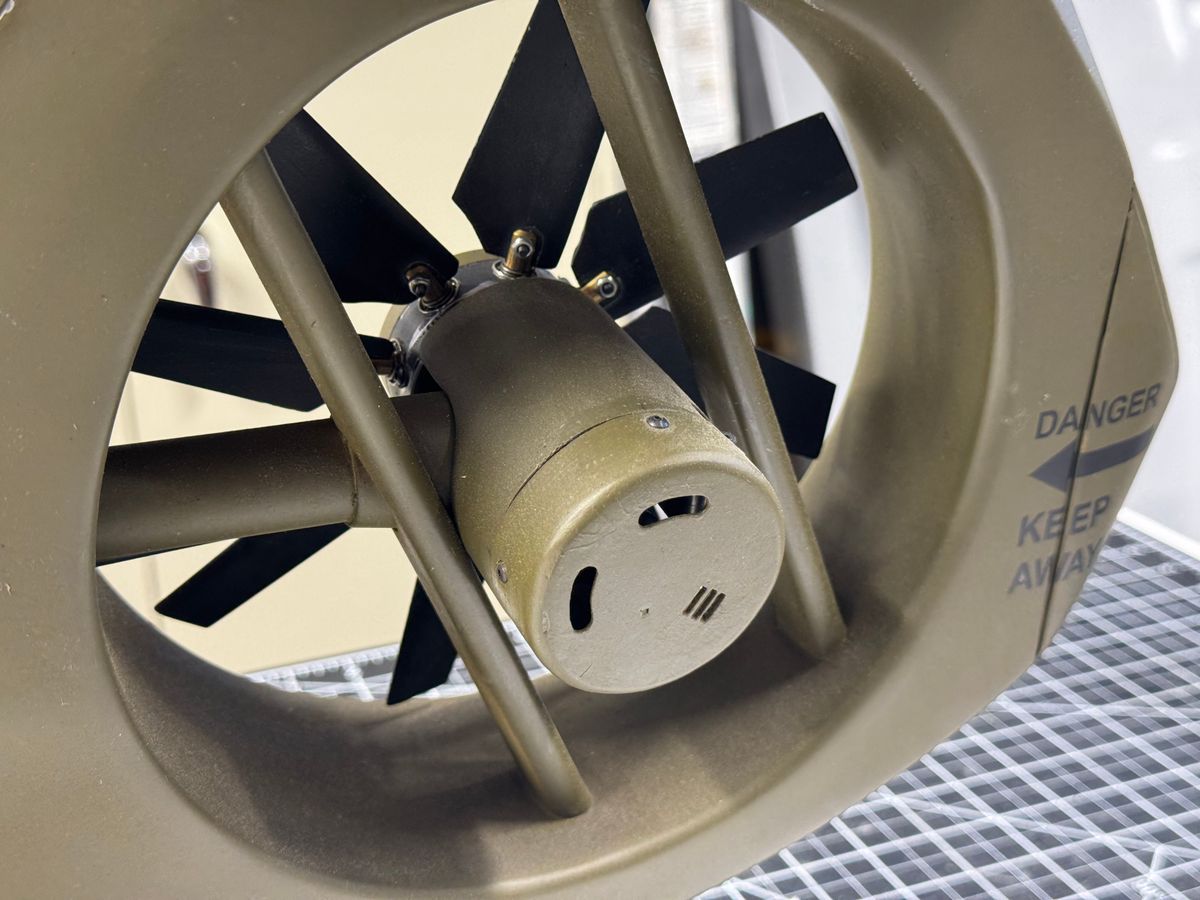
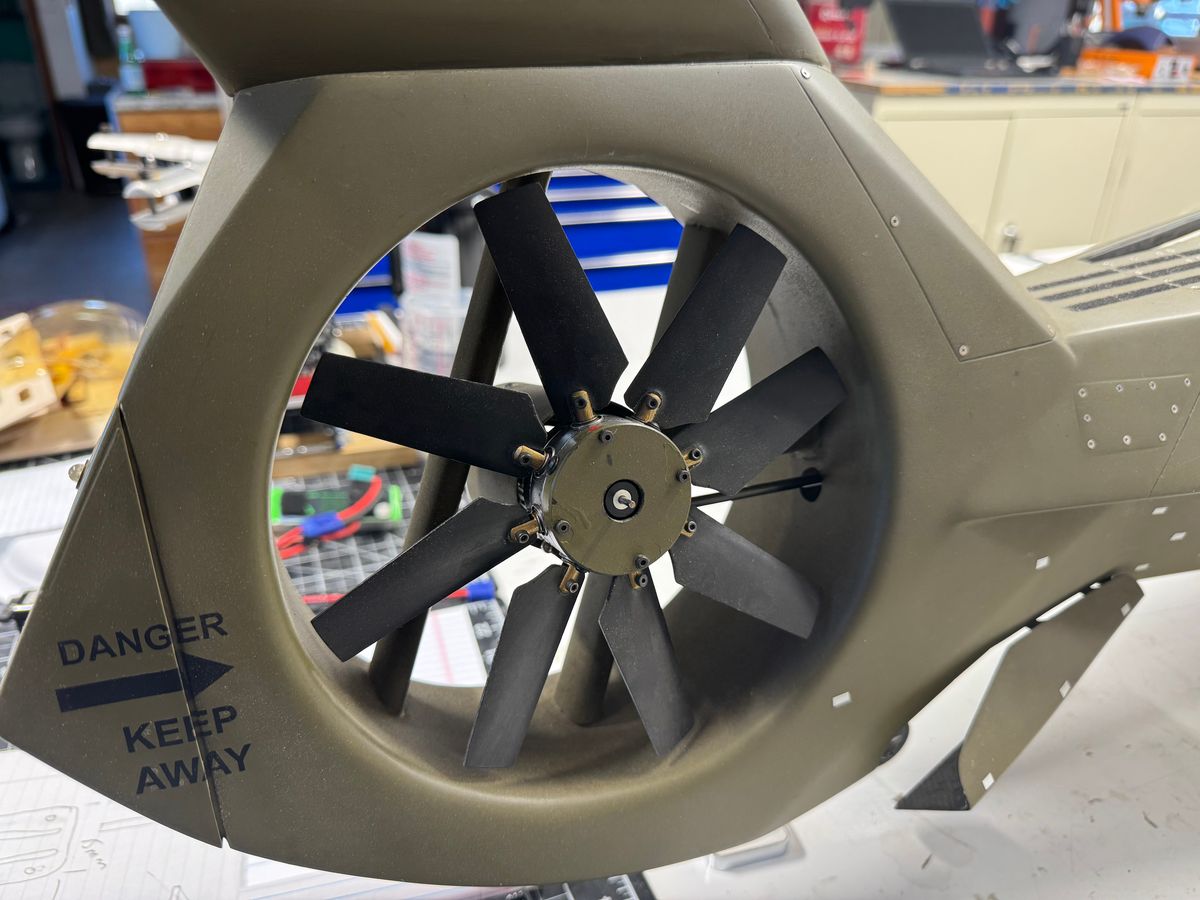
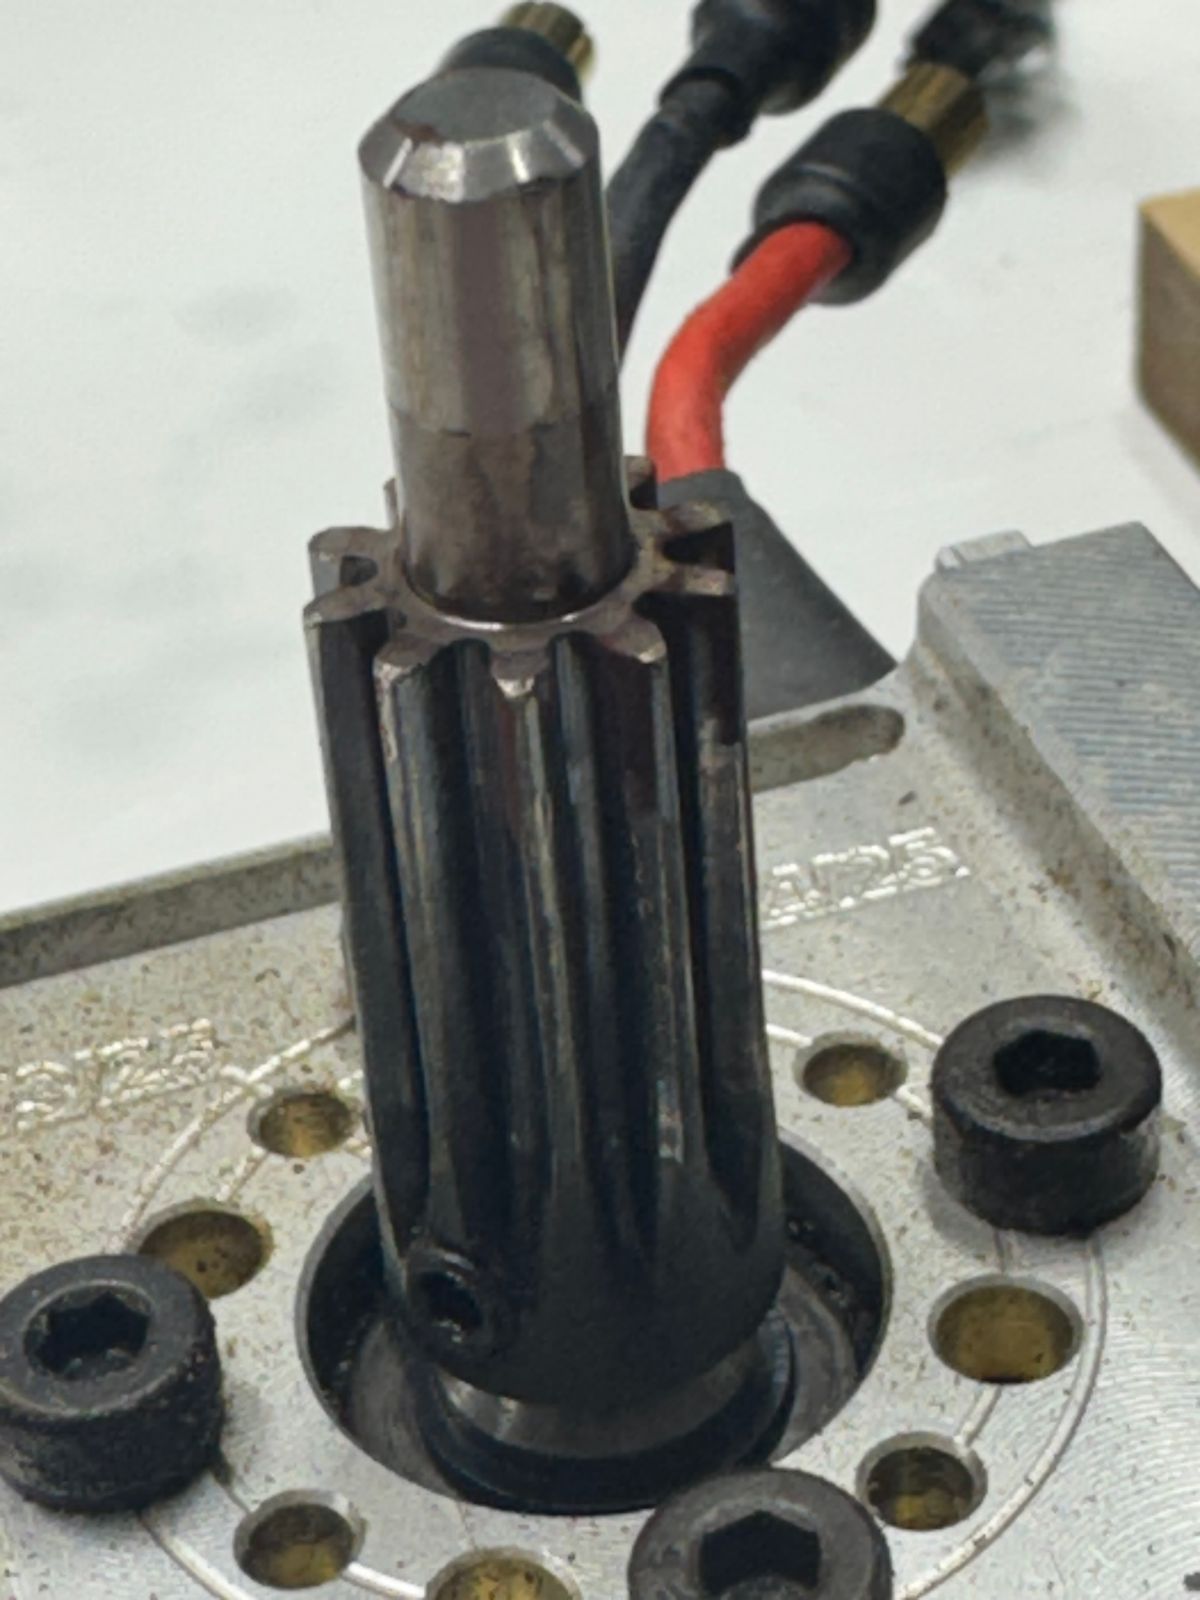
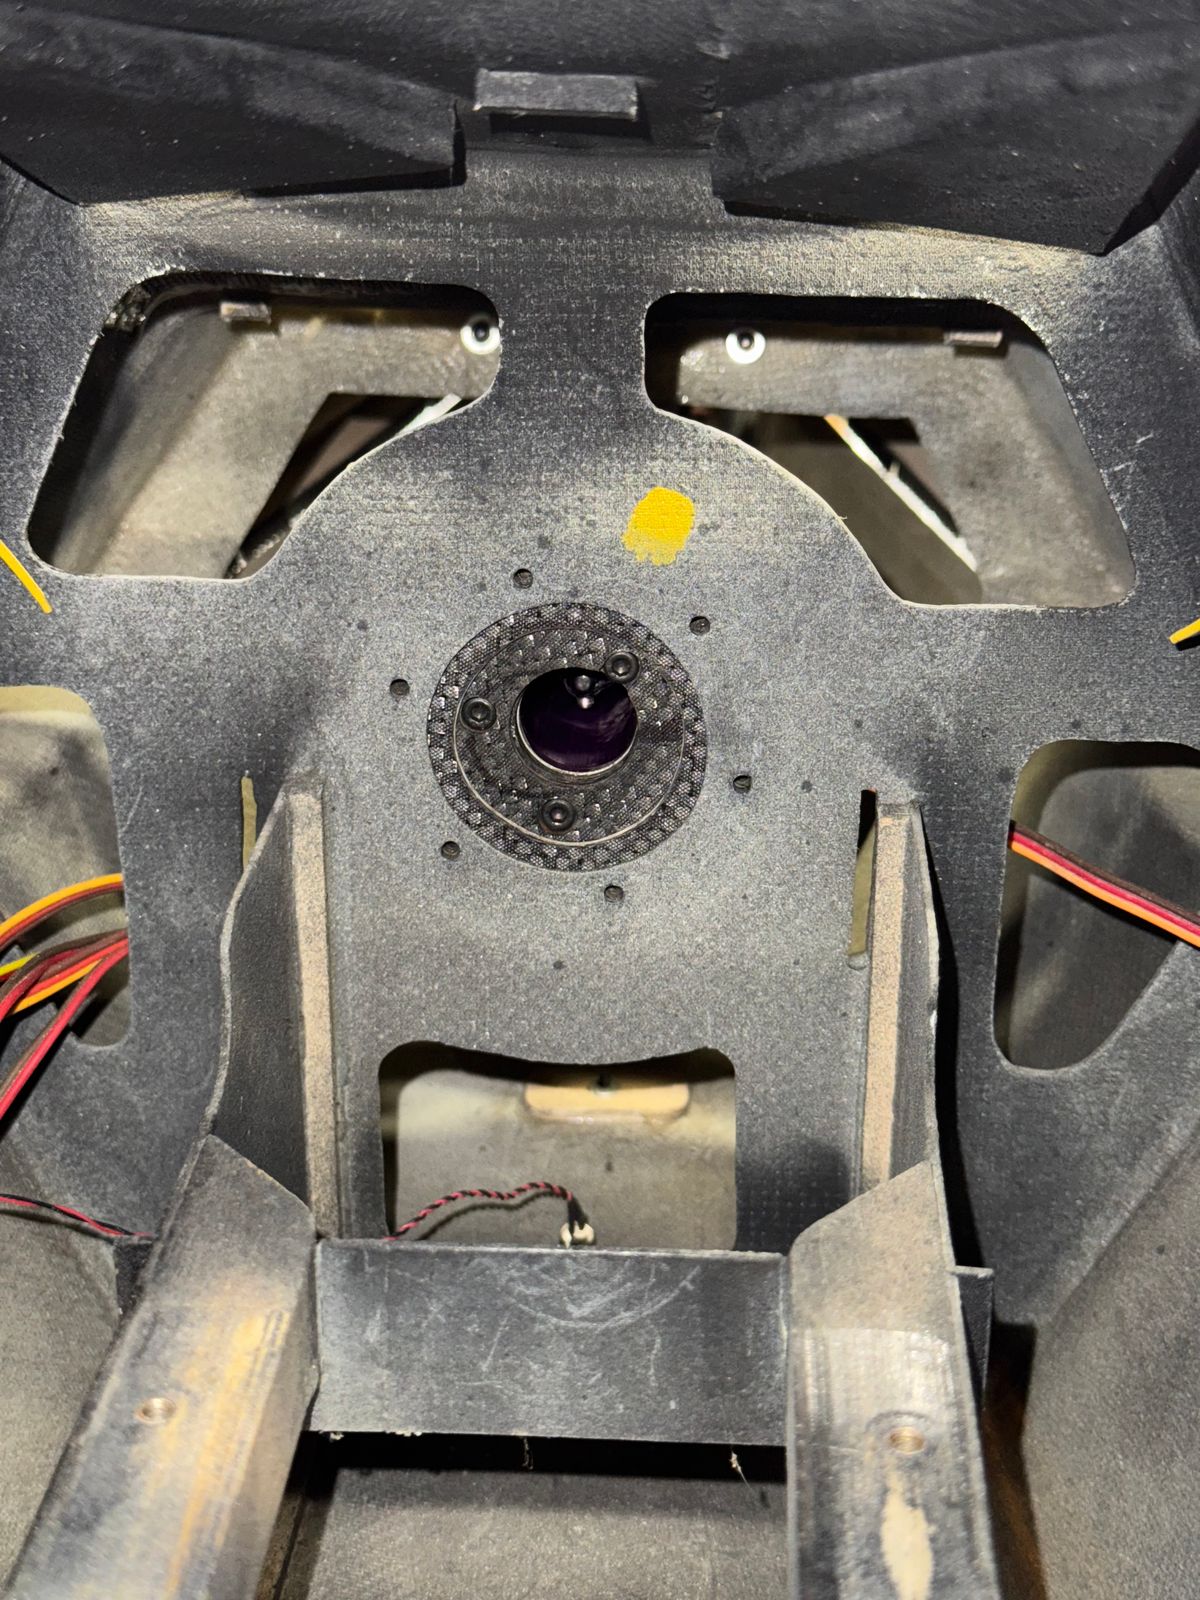
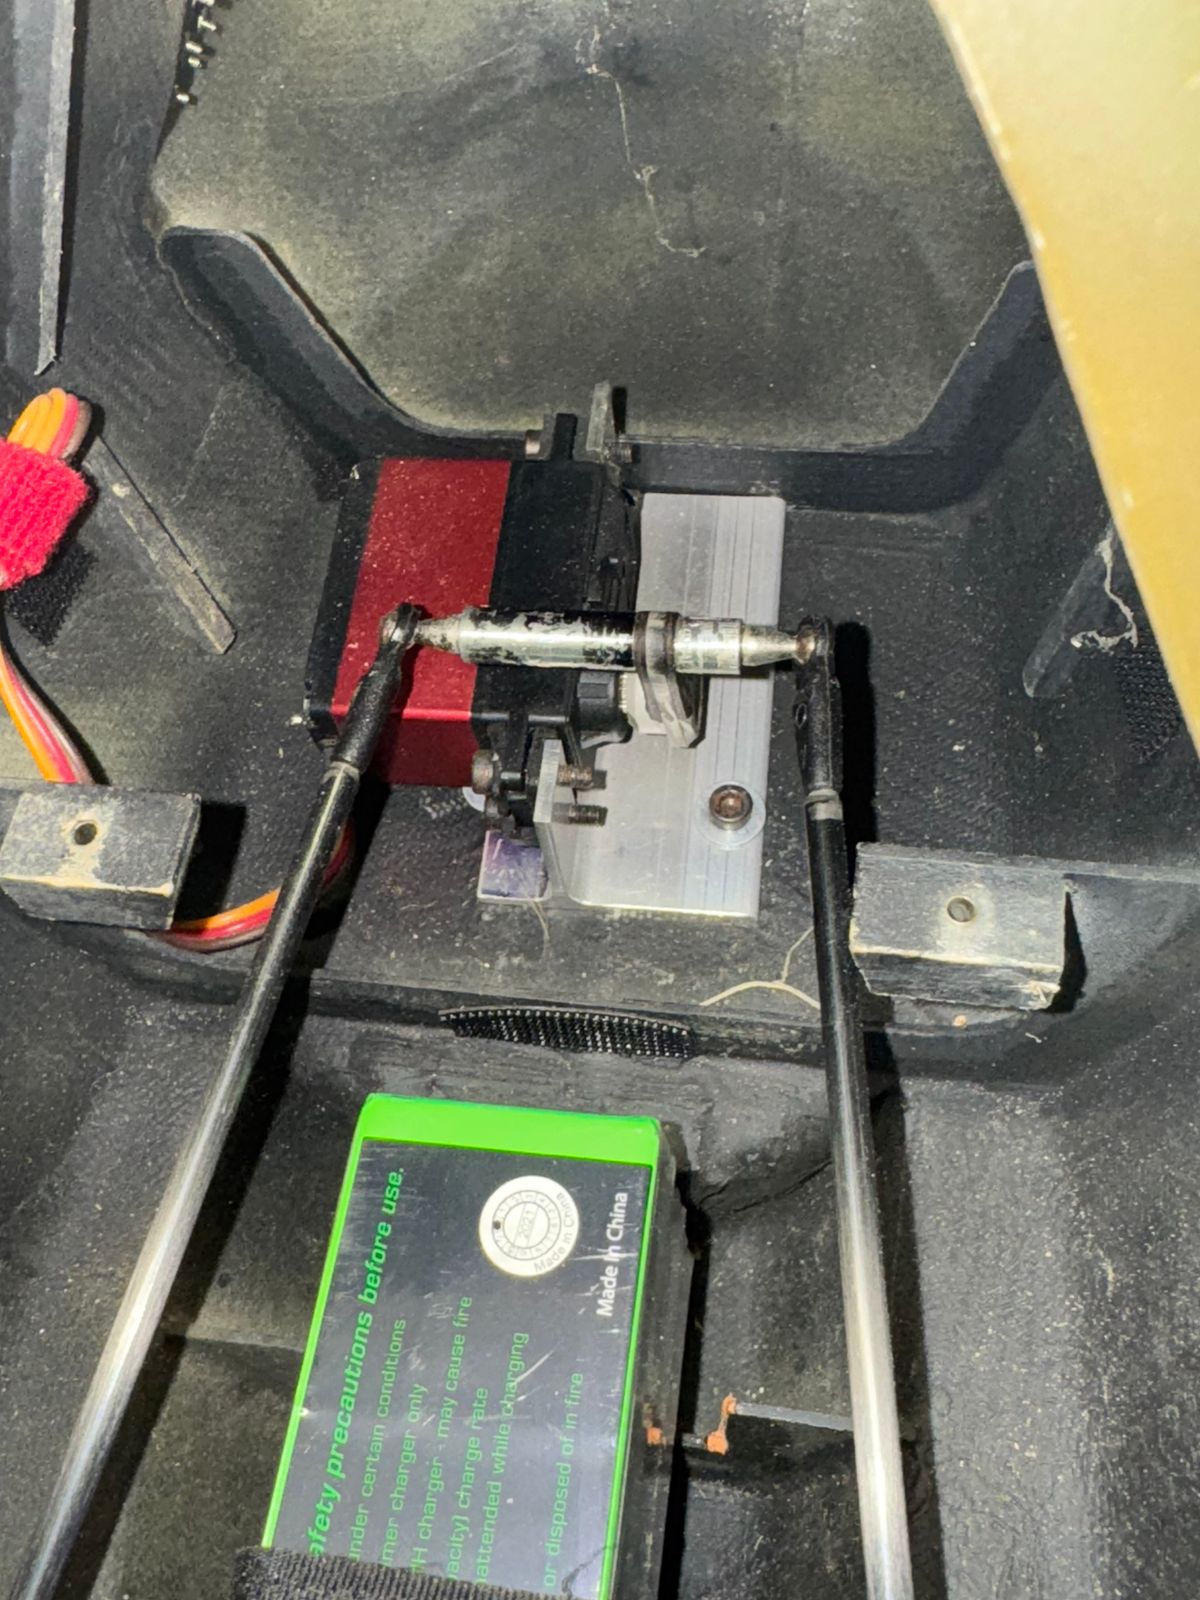
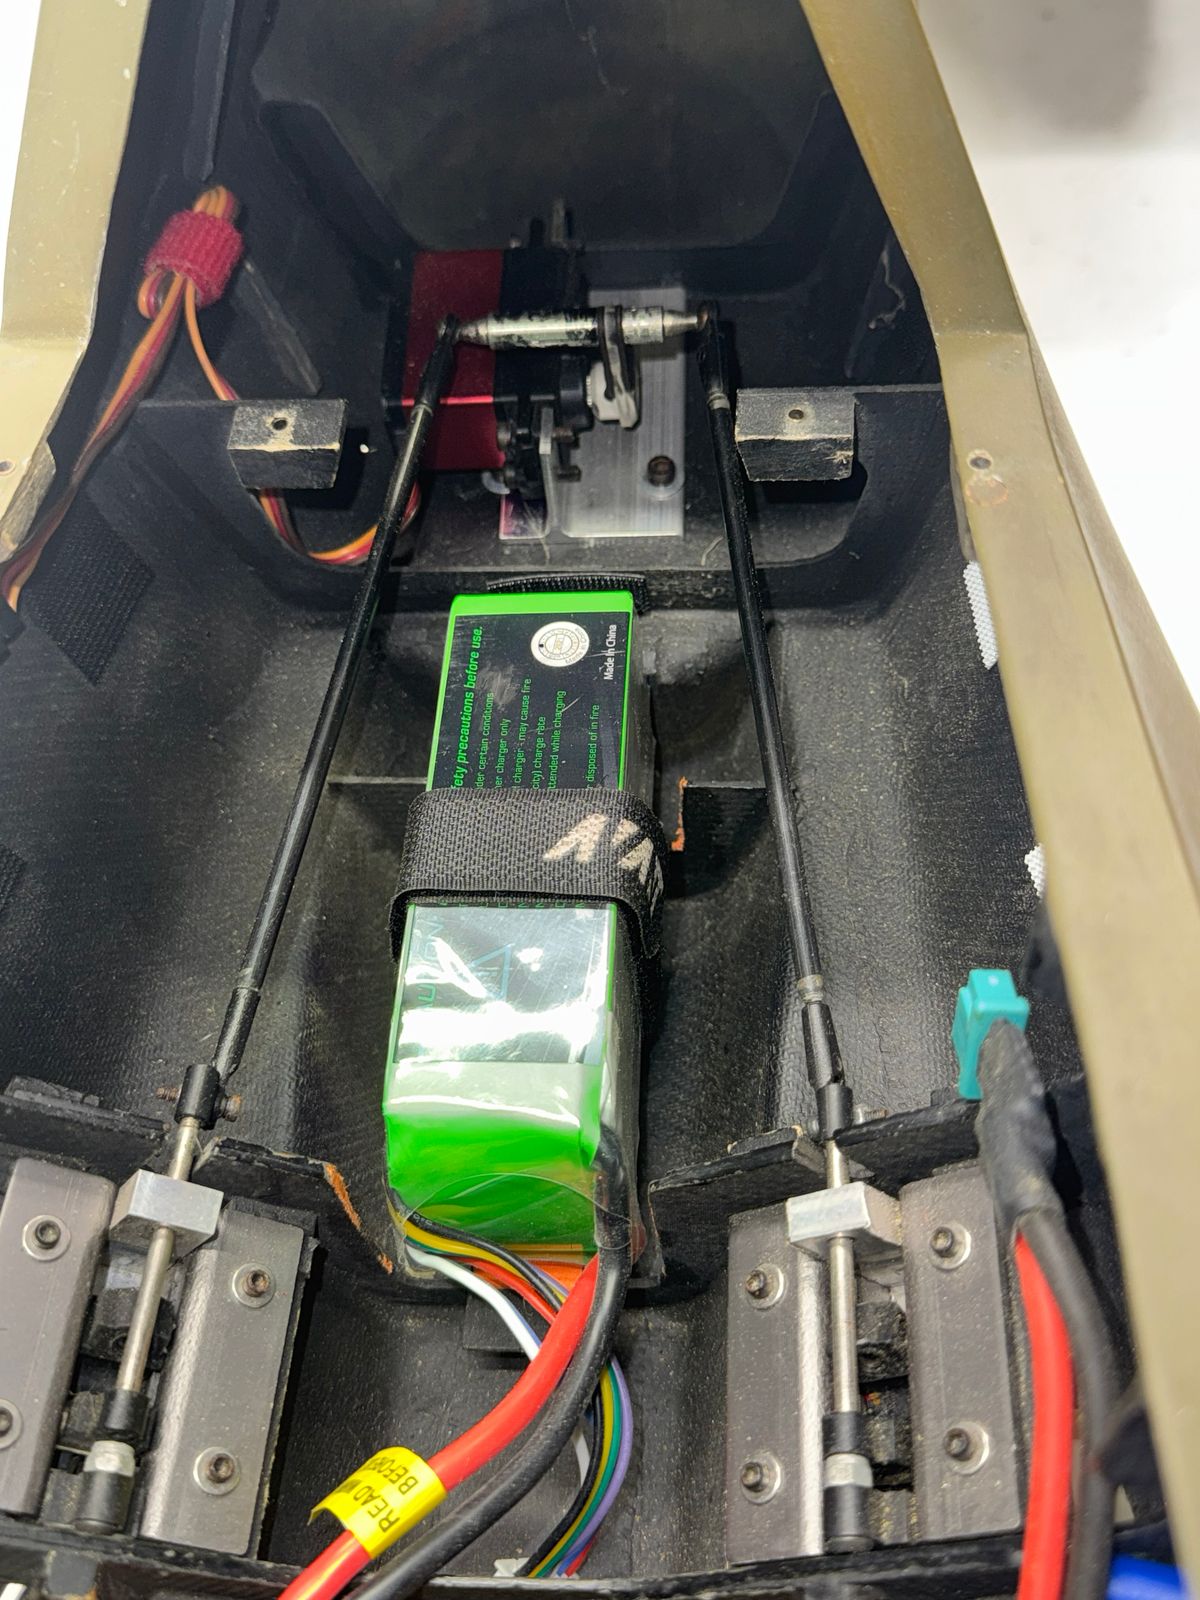
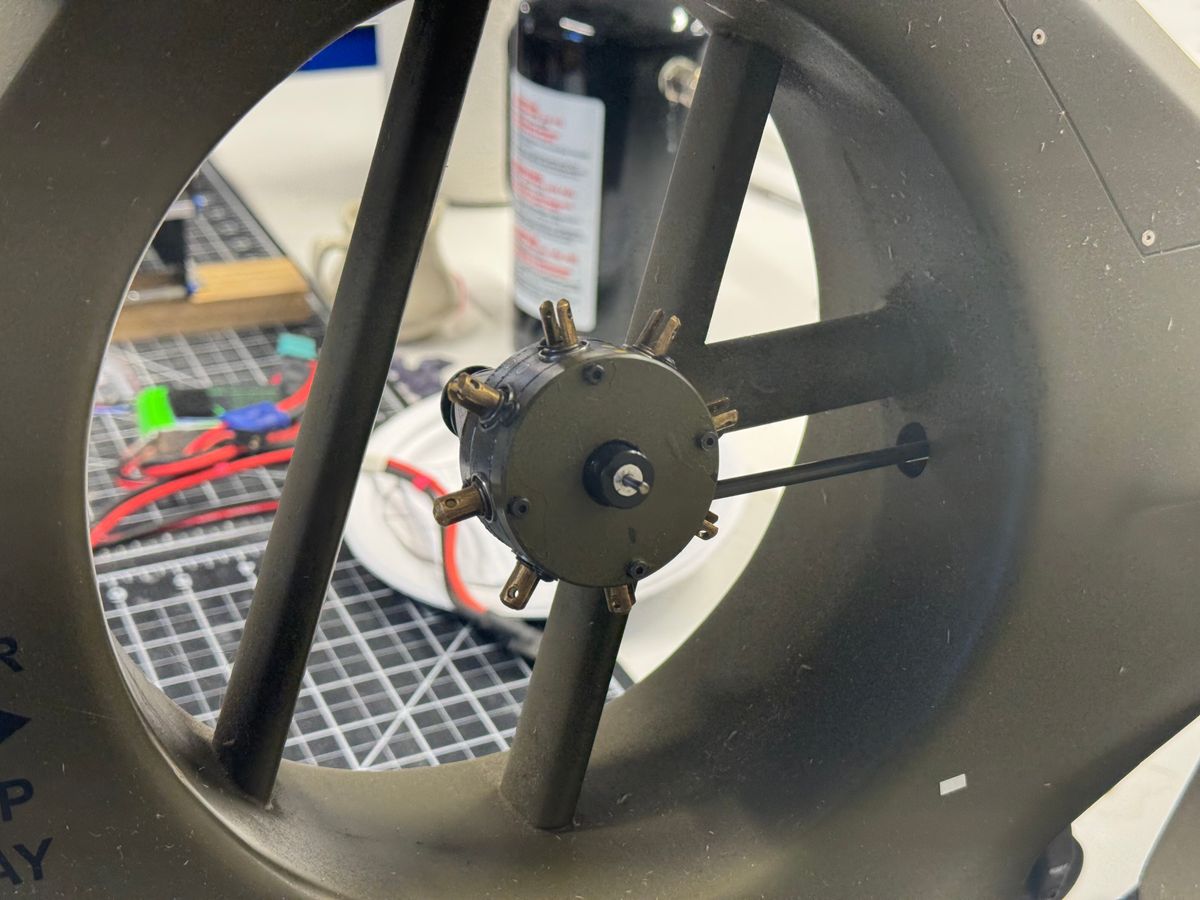
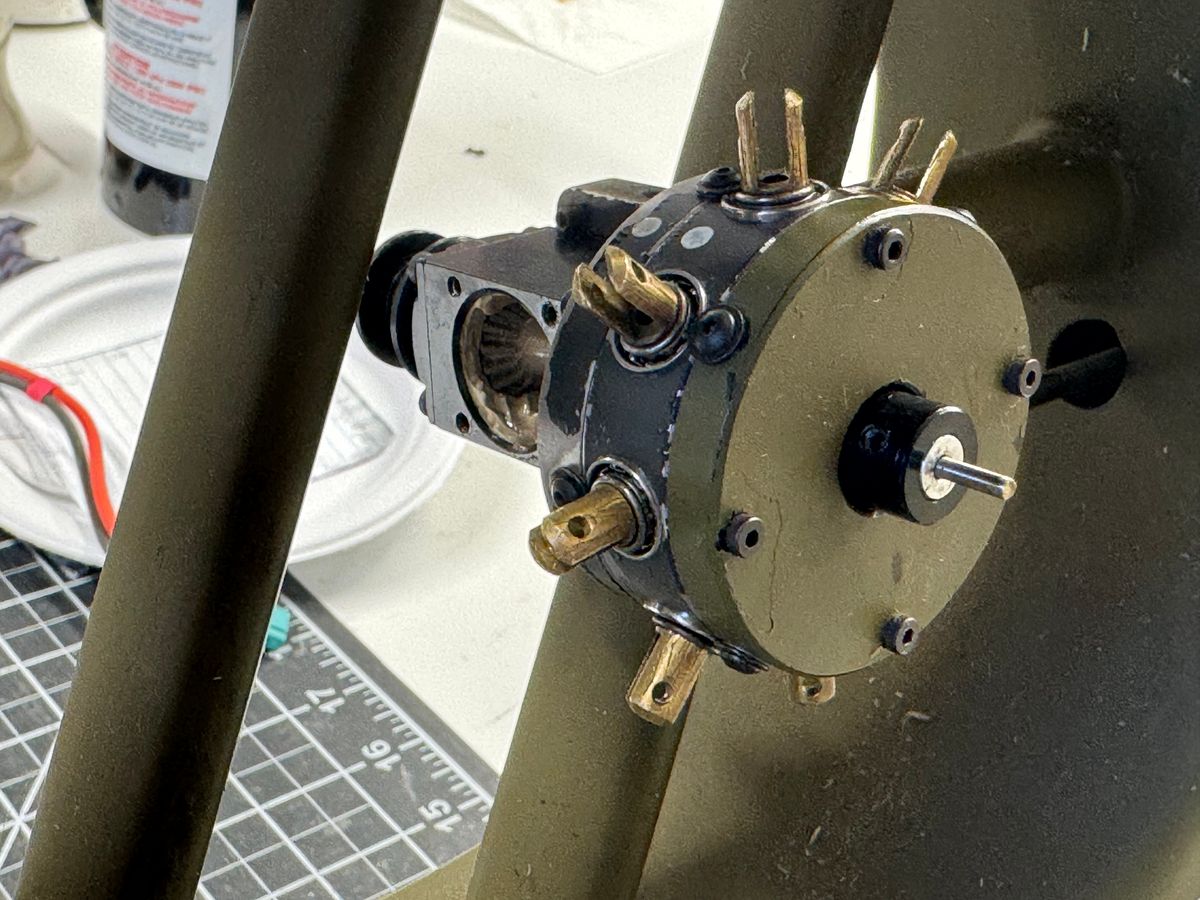
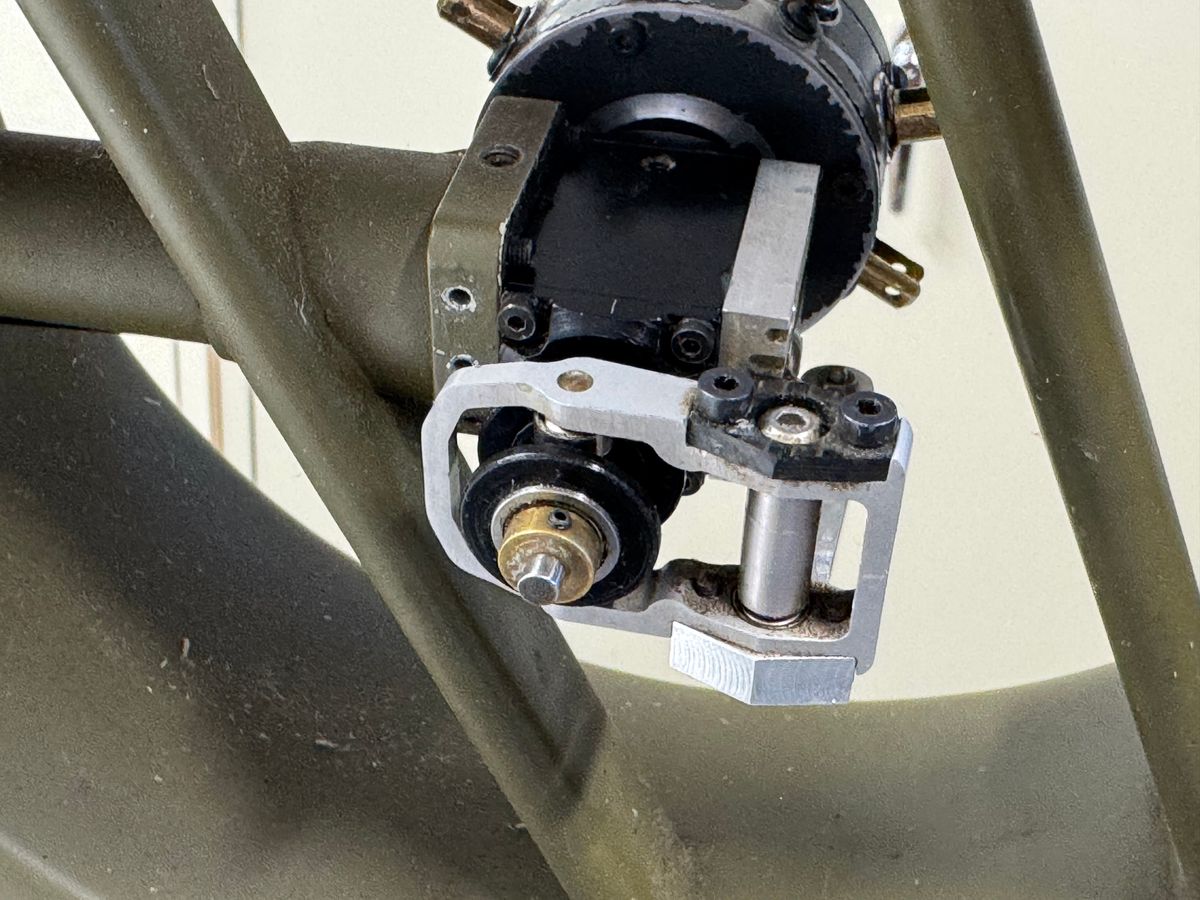
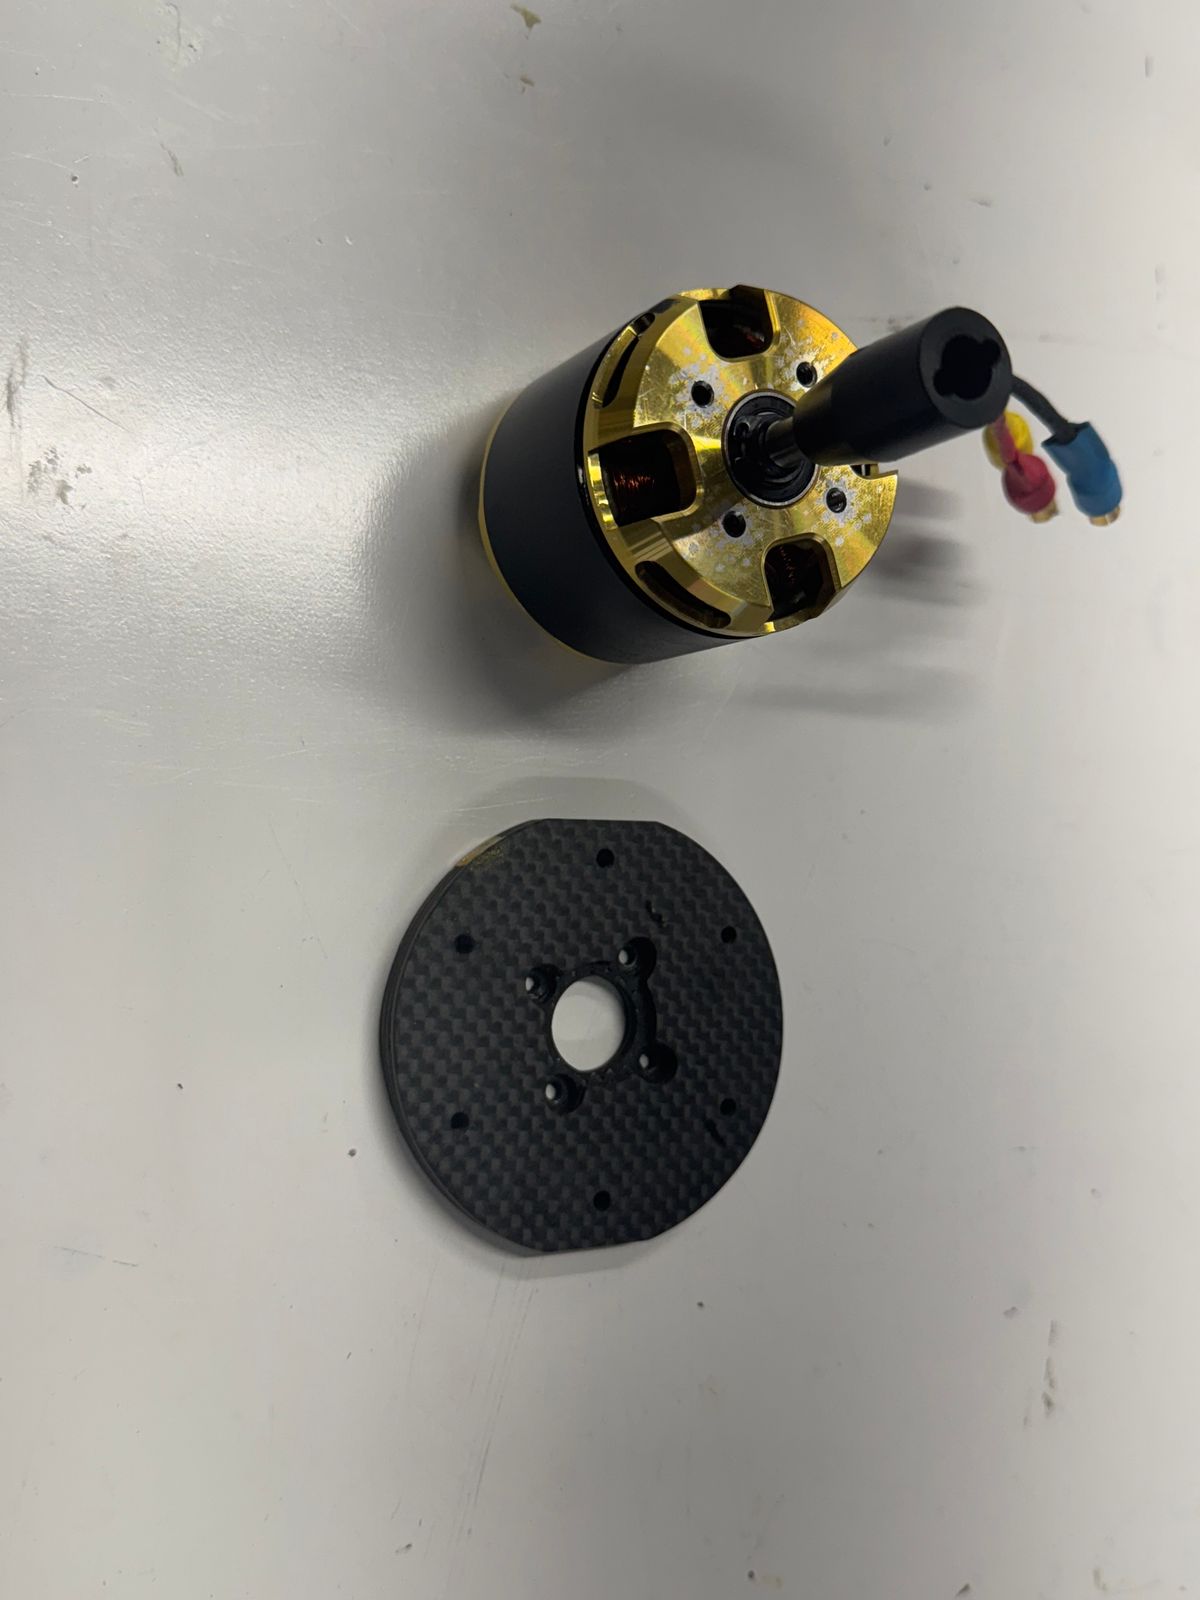
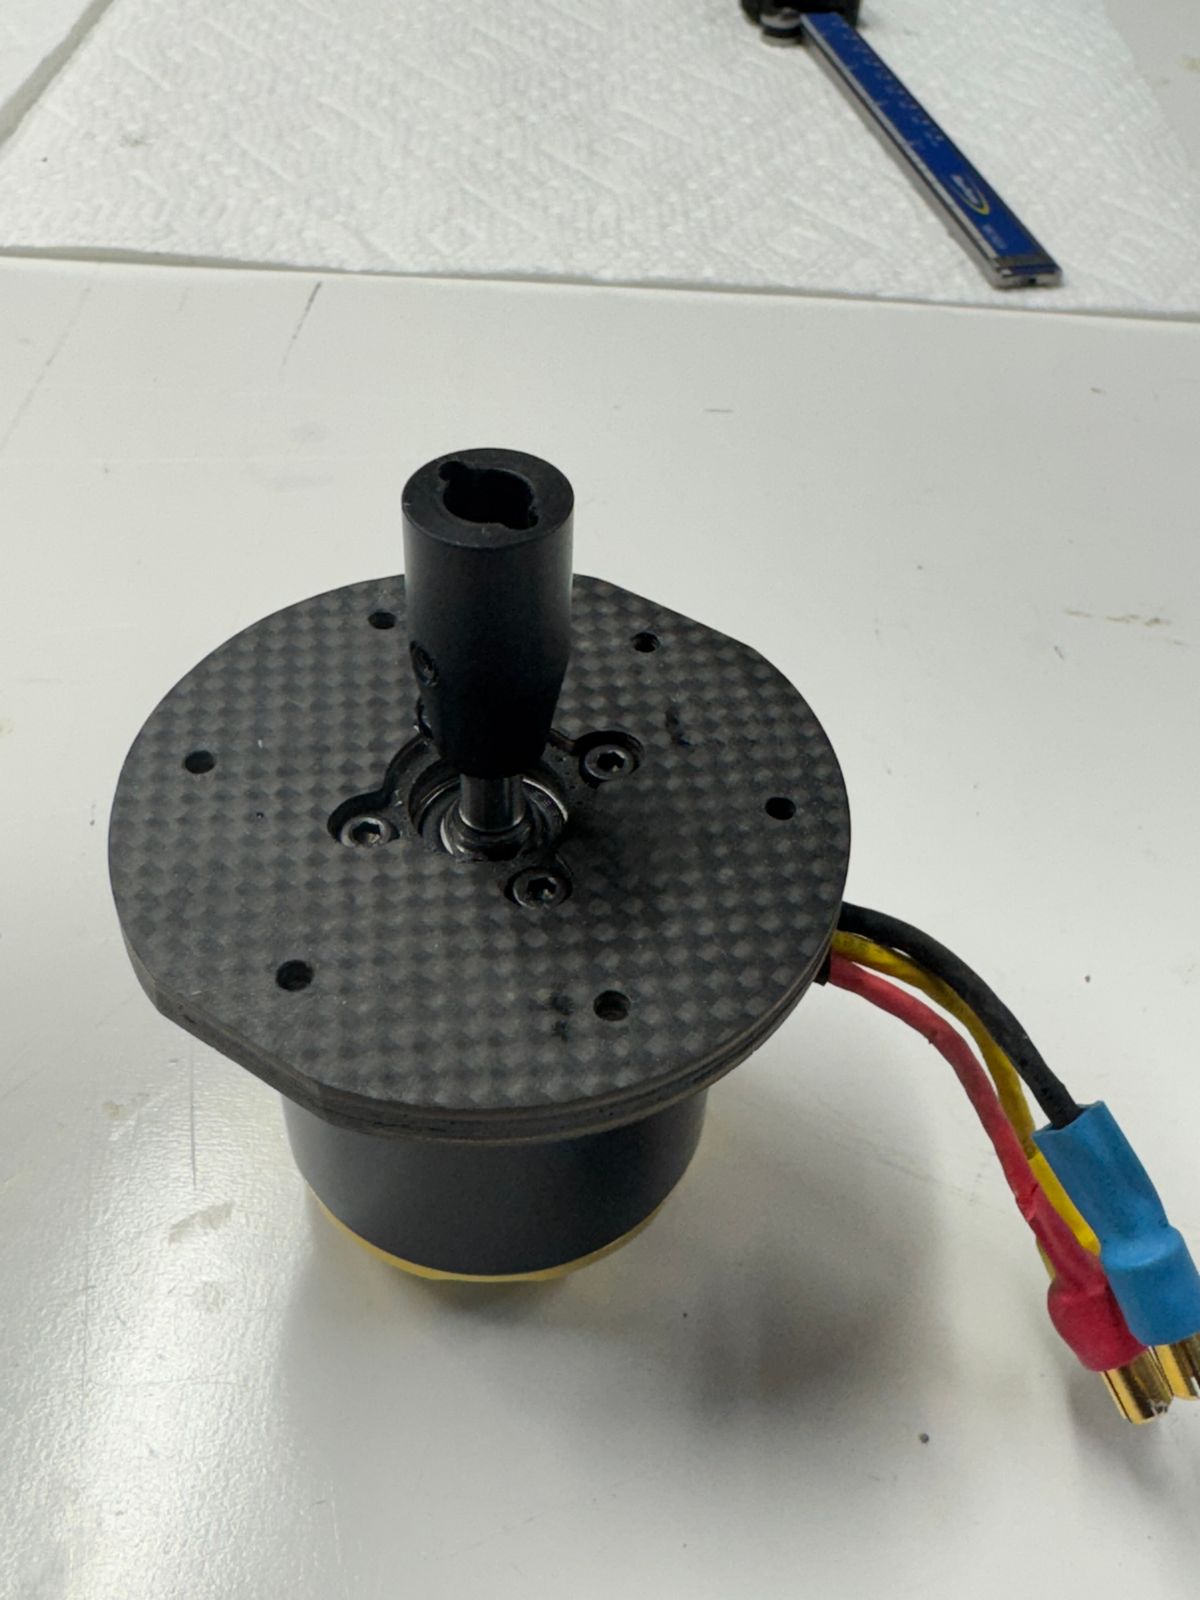
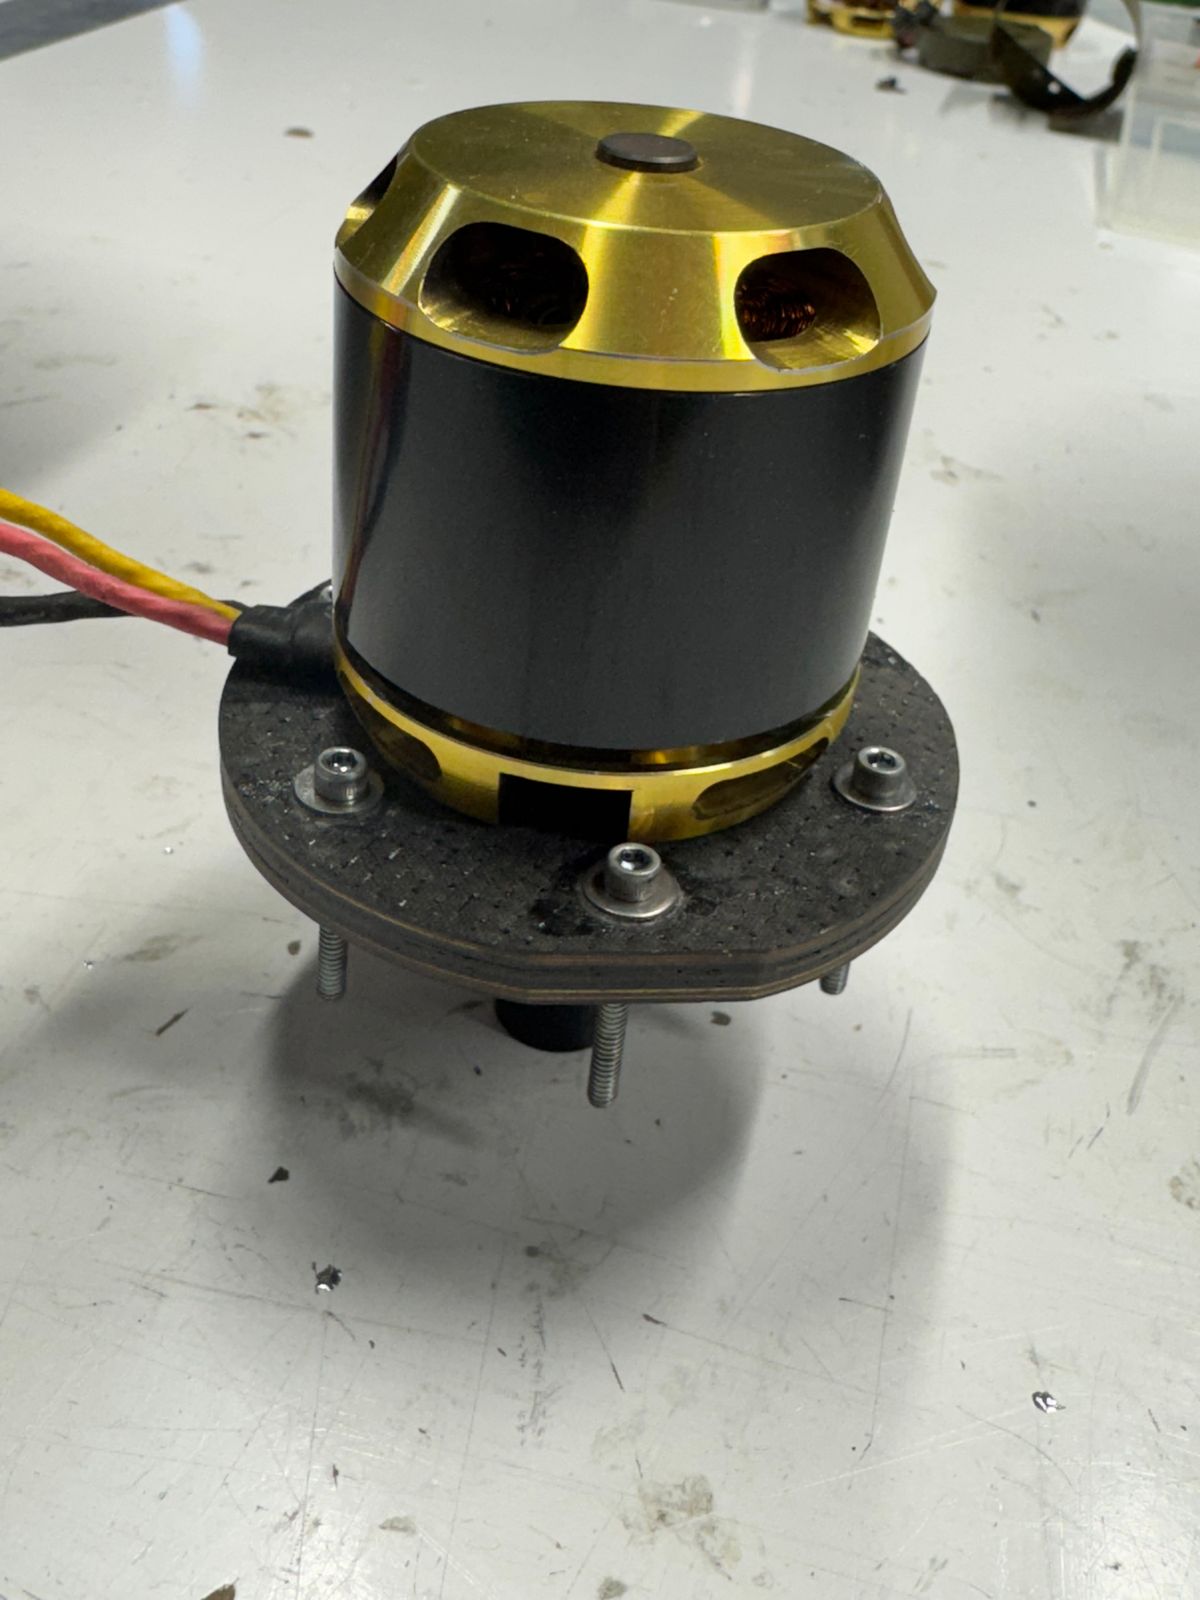
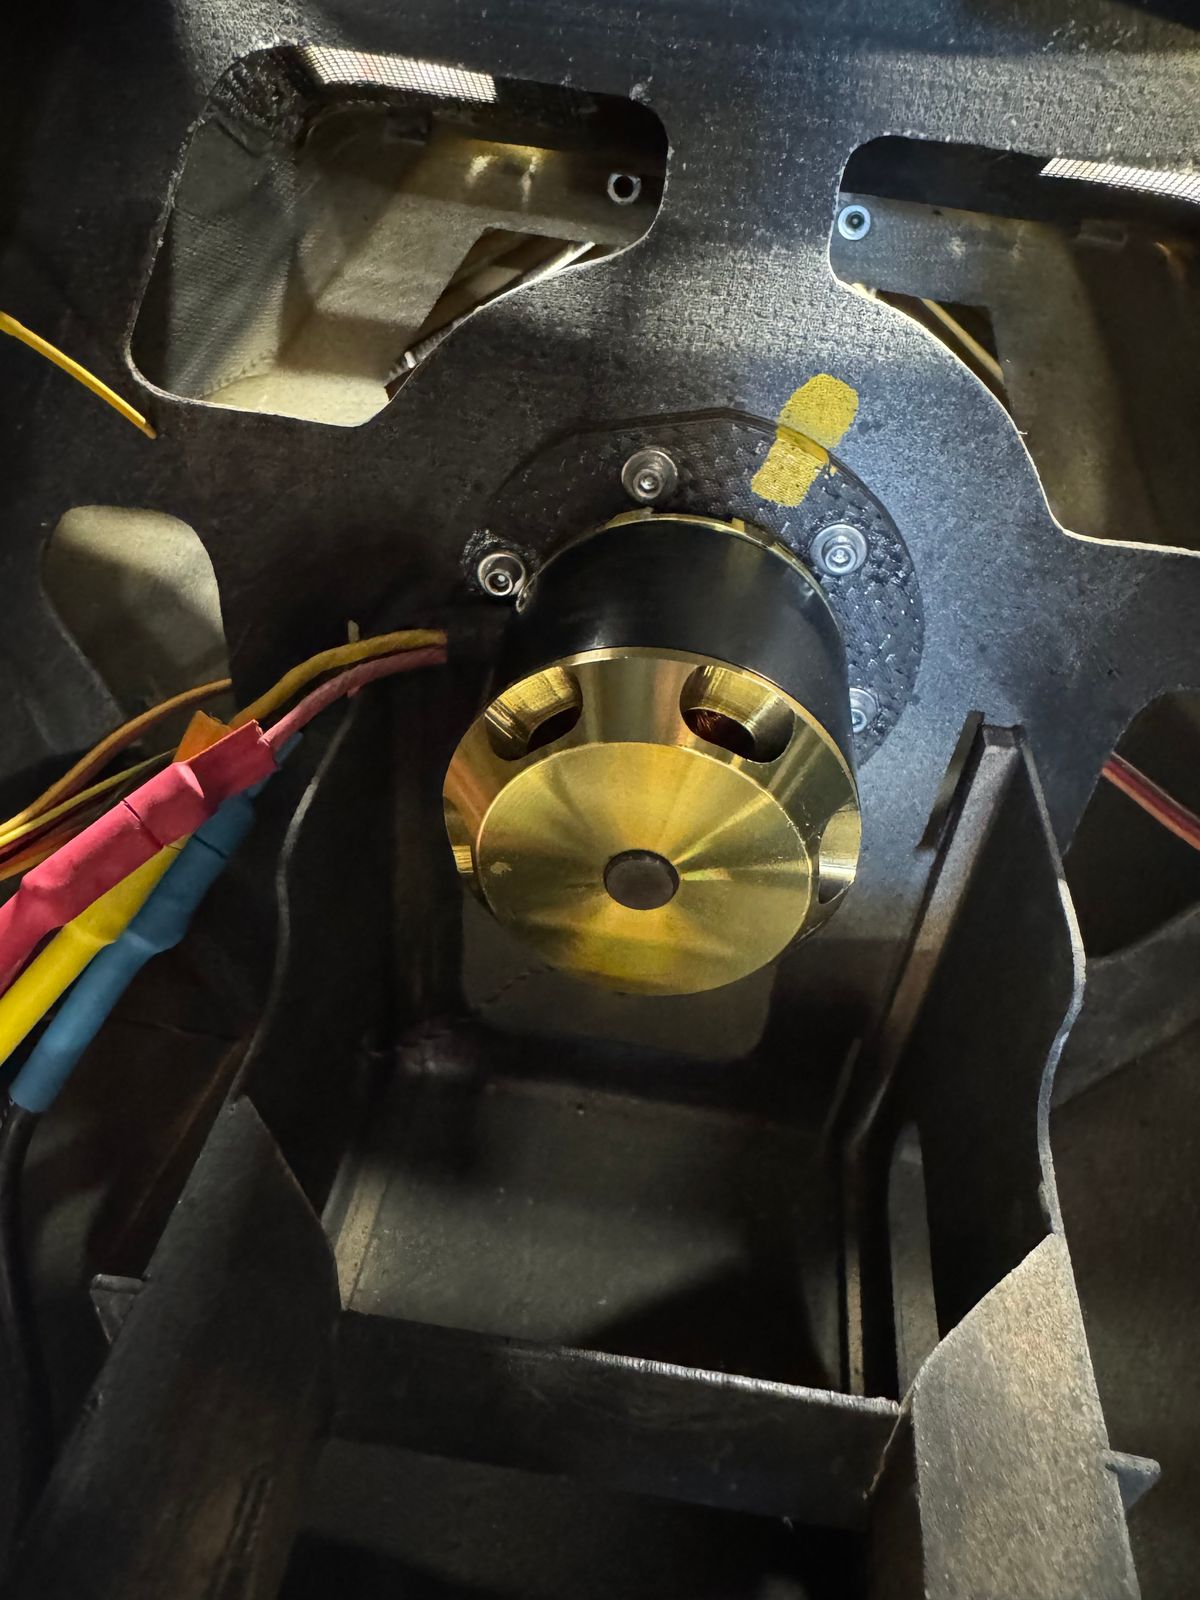
I was pretty busy over the weekend on Comanche. Everything looked very good. The motor and gear box bearings were replaced and the shaft bearings were inspected and lubed. The grip bearing were inspected and lubed. Cleaned and inspected re-shimmed the TGB gears from .27mm to .30mm to take out some end play from the new bearing install. All the bearing on the pitch control assemble replaced lined and re assembled.
Replaced main motor bearings waiting for a replacement motor shaft. Inspected and lubed all main shaft bearings.
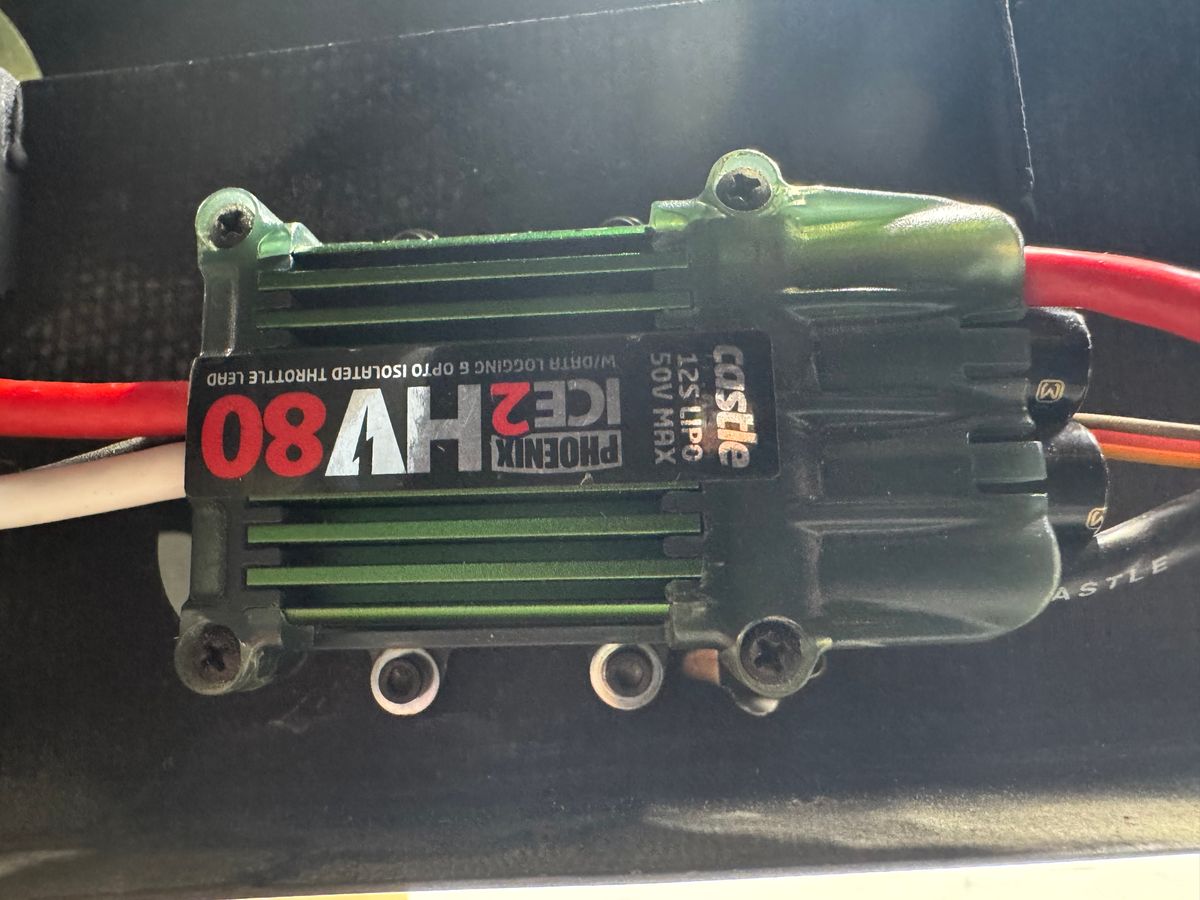
A few pics
Thanks for dropping by.
B
4 Comments
A short video I forgot to post.
https://www.youtube.com/watch?v=Y6fjuiG-bM0
What kind of mechanics is this?, looks very compact. Direct tail drive safes you a lot of mechanical transmission and weight.
Danny,
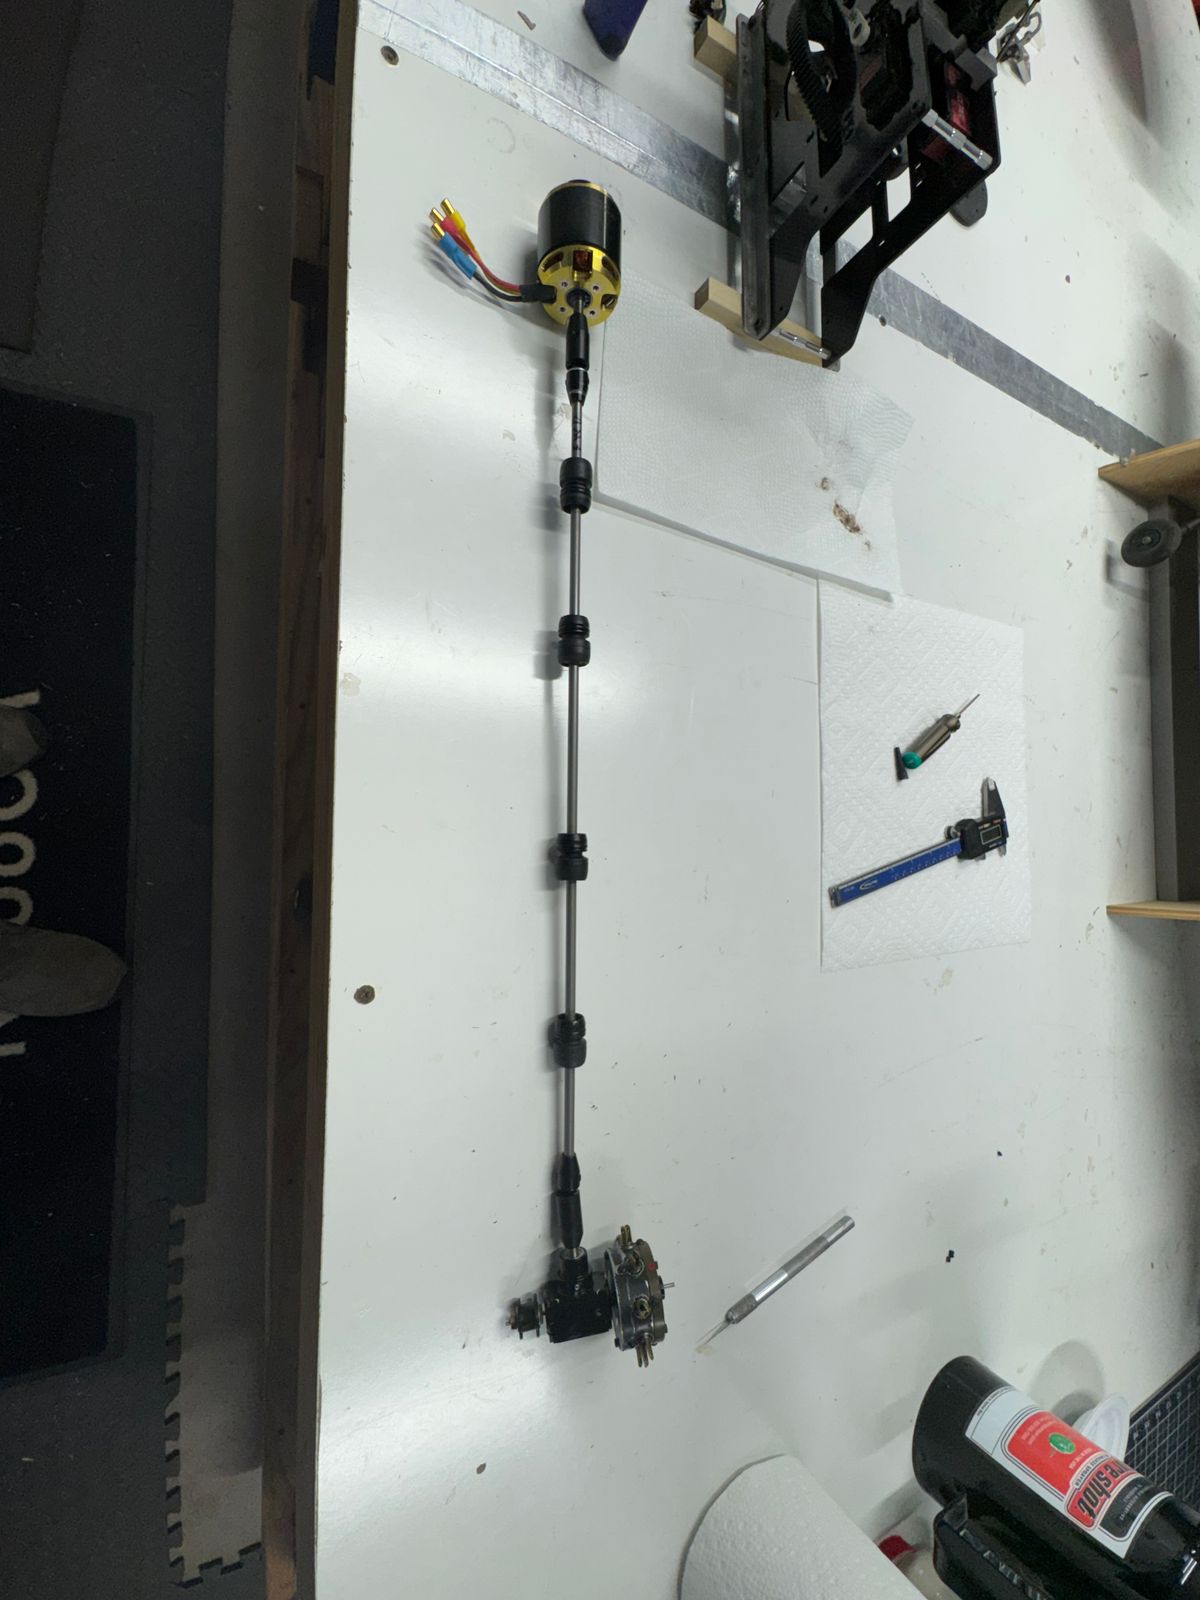
They are my design based on T-Rex 700 internals. The smaller tail motor is mounted just behind the main mechanics on a bulkhead and drives the Vario TGB and Fenestron assembly via a 6 mm torque tube and housing.
The torque tube and housing are roughly 20 inches long and uses 4 carrier bearings to support the shaft. I have turned the tail from 8500 to 10,500 RPM. It performs the best at around 9200 to 9500. The tail is 1 to 1 and runs on a 6s pack where as the main runs on 2 each 6s packs.
It did take some testing to get the tail ESC and gyro gains just right and working together. With the 1 to 1 drive, as the tail fan was under load, the speed would droop, maybe about 750 rpm, the tail gyro would add more pitch to maintain heading then the ESC would add more power to maintain speed, everything would catch up the tail gyro would reduce pitch causing what I called "gyro chasing".
The "happy" spot was reducing the ESC gain, running a slightly lower tail gyro gain and fan speed of 9300 RPM. Lower gains reduced the correction time to the ESC and tail gyro along with a little delay in the tail gyro made a nice flying machine. With the gains on the lower side it does not perform as a conventional tail but does fly sideways at a pretty decent speed.
The first vid was 14 years ago getting stuff sorted out. The second was about 10 years ago with some sideward flight.
Sorry for the long explanation.
Enjoy the video
B
https://www.youtube.com/watch?v=lgYc9h_GuM8&t=14s
https://www.youtube.com/watch?v=Qk1nG8nxJG0&t=10s
The best of the best!!!